
AI robot for factories and manufacturing sitesFrom robot testing to automation of processes that lack manpower.
Using humanoids, dual-arm robots, and mobile manipulators, we will use actual machines to verify human work that has previously been difficult to automate. EmplifAI provides Unitree G1 to major manufacturers and continues to support multi-month testing of robot. We will propose a machine that suits your process without relying on a specific manufacturer.
Consult about robot verification at the factory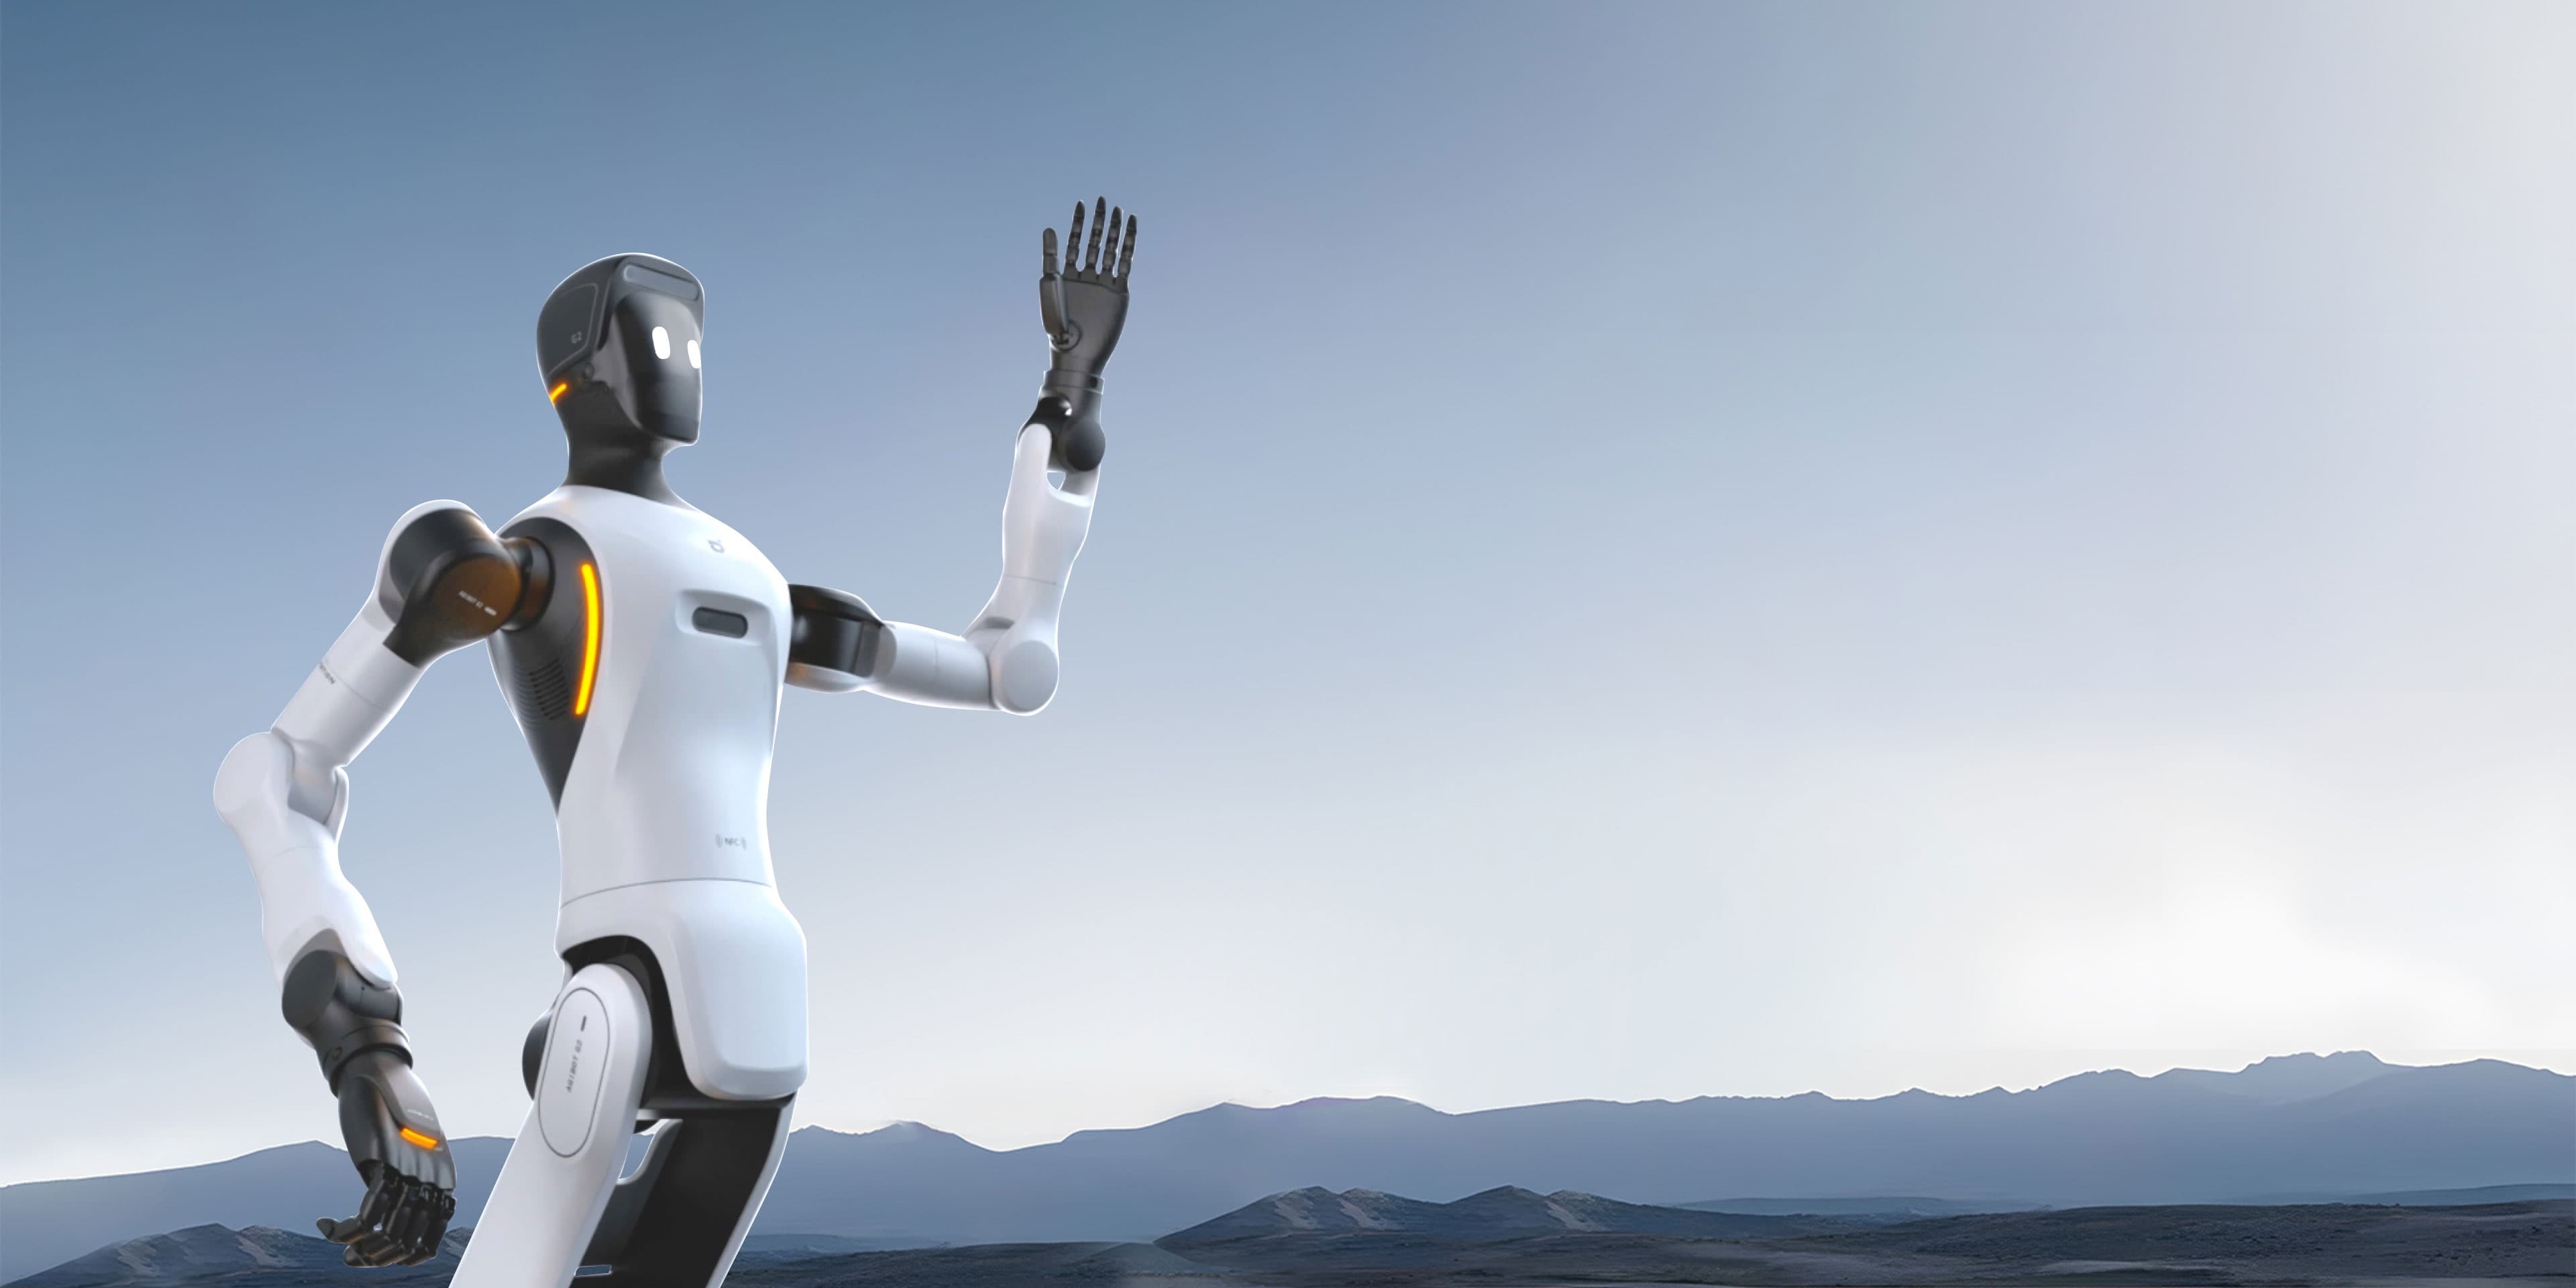
To processes that cannot be reached with existing industrial robots
Although factory automation has long been in the works, there are reasons for the remaining processes. The shape and position of the object changes every time, there are many types in small quantities and there are many setup changes, and the quantity is not suitable for special equipment. These processes were difficult to handle with fixed industrial robots.
Humanoids and dual-arm mobile manipulators are attracting attention because they can fill this gap. The walkways are designed for people, the height of the workbench is high, and existing jigs can be used as they are, so they can be brought to the job site without having to rearrange the line. The essential difference is that it can be placed directly in the same place where people were moving.
On the other hand, current humanoids cannot work with the same speed and precision as humans. That's why it's important not to make judgments based on catalog values, but rather to evaluate the product by actually using it in your own company's target objects and processes. It is for this reason that we recommend that you enter EmplifAI from robot verification.
Tasks subject to verification/automation
First, we focus on one process and test it on an robot, determine the scope of what works, and then expand the process.
Parts transportation
Transporting parts between processes and warehouses. With a mobile manipulator, you can handle not only transportation but also loading and unloading at the storage area.
picking
The task of removing objects from boxes or containers. For objects whose shape and orientation are not constant, an approach that uses visual perception and movement to learn is effective.
Setting on the jig
The work of placing and removing the workpiece before and after processing on the jig. Check with the robot whether the existing jig can be used as is.
Assembly
The work of fitting parts together. Since precision in force adjustment and positioning is required, we will start with targeted verification.
machine tending
Attachment and detachment to machine tools. Verify whether it can be handled as a series of steps, including opening/closing doors and button operations.
Appearance confirmation
Visually check for scratches and chips. We will proceed in stages, including mounting a camera, recording, and automating judgment.
Button/lever operation
Work that involves touching equipment operation panels. The advantage of using a humanoid is that it can be automated without modifying the equipment.
simple repetitive work
A process of repeating the same movements. It will be easier to see results if you start with tasks that are burdensome and difficult to retain.
Select a machine according to the process
We will propose machines based on the target work and site conditions, without relying on a specific manufacturer. Available for both purchase and rental.
AgiBot G2
A semi-humanoid that combines object manipulation and movement mechanisms with its dual arms. This configuration is designed for use in industrial applications.
Unitree G1
A small humanoid with the most proven track record in robot verification. First, we will move on to the stage where we can operate it on site and evaluate it.
Unitree H2 / H2 Plus
Life-sized humanoid. Suitable for verification assuming the same working height as a person.
Realman RMC-AIDAL
Semi-humanoid. It supports introduction for research and development purposes and secondary development.
Unitree Go2
Quadrupedal robot. Suitable for patrolling and inspecting premises with steps and outdoors.
OpenShell
A dual-arm mobile manipulator developed in-house. Since the configuration can be changed, it can also be used as a verification platform.
How to proceed from robot verification to automation
We will not immediately introduce it into production. After confirming feasibility with a one-step PoC, we will expand the scope and number of units.
- 01 Process selection
- We sort out the shape, weight, variation of the target object, takt time, and human burden, and decide on the first process to be verified.
- 02 Selection of robot and configuration
- Consider the required payload, reach, degree of freedom, movement method, and hand. You can rent the robot to try it out before purchasing.
- 03 Actual machine verification (PoC)
- We move the object at the actual site or at our company. Measure the success rate and takt time and identify the conditions for success.
- 04 Movement development/learning
- In addition to controlling using ROS 2 or the robot SDK, you can also choose to learn movements from human work using imitation learning or VLA.
- 05 Operation with teleoperation
- Before making it fully automatic, we also use remote control to turn the site around. Learning data is accumulated during operation.
- 06 Expanding the range
- Based on the established process, it is horizontally expanded to adjacent processes and other lines. Additional numbers will also be decided at this stage.
Technology supporting automation
Imitation learning/VLA
The robot learns its movements from human work demonstrations. This is effective for processes where the operation cannot be written down in a program.
Teleoperation (remote control)
We have implemented body-sharing telepresence that transfers the operator's body movements and intentions to a humanoid in real time.
Sim2Real
We will move from learning and evaluation using NVIDIA Isaac Sim/Isaac Lab to the robot. Verification can proceed without stopping the robot.
ROS 2/SDK control
We support control and collaborative development using SDKs and ROS 2 for robots from various companies. The design also includes connections with existing equipment.
Collection of training data
We design the target work, equipment, collection volume, and quality standards, and acquire data using the robot. This process is the foundation for automation.
Development of dual-arm mobile manipulator
We handle everything in-house, from the design and development of the robot with dual arms and a movement mechanism to the integration of the actual robot.
Achievements in the manufacturing industry
We provide the Unitree G1 to major manufacturing customers in order to use actual machines to determine whether or not robots can be used at manufacturing sites, and support technical verification and operation. Verification is ongoing for several months.
In addition, as part of the development of humanoid motions for use in the field, we are working on control, motion generation, and robot verification to reproduce human motions with robots.
We also accept consultations from the stage where there are no engineers within the company who can handle the robot that has already been installed. We will accompany you from control/operation development to established operation.
Frequently asked questions
Can humanoids really be used in factories?
It depends on the process. Although there are still challenges in being able to work for long periods of time at the same speed and accuracy as humans, it is a realistic option for processes where it is difficult to build specialized equipment for small-volume, high-mix production, or for simple repetitive tasks that place a heavy burden on humans. We recommend that you make your decision based on actual testing using your company's products, rather than looking at catalogs.
Which process should I start with?
It is suitable for processes where there is little variation in the objects, there is plenty of takt time, and there is a large human burden. First, we conduct PoC on one process, identify the conditions that hold, and then expand the scope. You can consult with us about process selection.
Is it necessary to modify existing equipment or lines?
The advantage of using a humanoid, dual-armed robot is that you can use an environment created for humans as is. We will use the robot to check whether the aisles, workbench heights, existing jigs, and equipment operation panels can be utilized. We propose a configuration that minimizes modification.
How do you ensure safety?
The distance to workers, stopping conditions, and whether or not fences or safety devices are required are designed according to the target process and site conditions. From the verification stage, we proceed by determining safety conditions that assume actual operation.
Can I try before I buy?
You can start by testing the robot by renting it. The biggest loss is to find out that you can't use the machine after purchasing it, so we recommend renting the machine and trying out the process first.
There are no engineers in the company who can handle robots.
We receive many inquiries regarding this situation. We will accompany you from control and operation development to established operation, and if necessary, we will also support handover to a state that can be handled in-house.
Consultation on robot verification at factories and manufacturing sites
Please let us know the target process, objects handled, and current issues. You can consult with us even if you have not decided on the robot or are unsure of which process to start. We will make a proposal starting from a 1-step PoC.
Consult about robot verification at the factory