
Sim2Real development supportAt NVIDIA Isaac Sim・Isaac Lab,
From simulation to robot verification.
We support the development of learning and evaluating robot work in a virtual environment and applying it to robots. From environment construction to learning and adjustment of errors with the robot, we will propose a range of work to suit the current issue.
Consult about Sim2Real development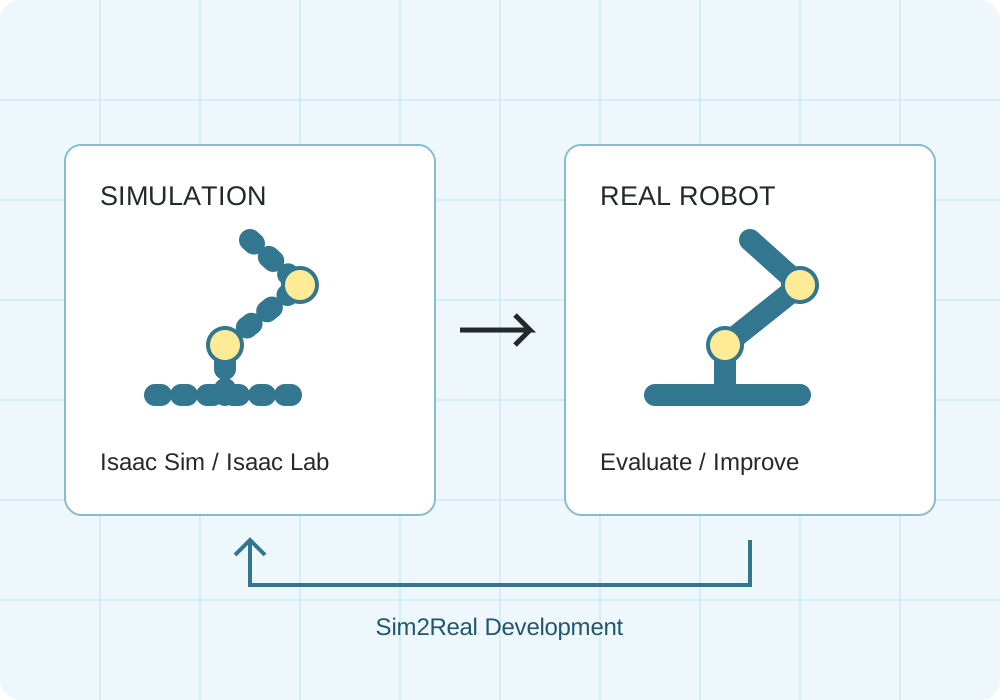
Organize where to proceed with Sim2Real
You can consult with us about issues such as ``I want to introduce Isaac Sim,'' ``It works in simulation but is not stable on the robot,'' and ``I want to create a verification environment for robot learning.''
Simulation environment construction
We organize the target robot and work environment, and support the creation of the environment necessary for verification, such as introducing the model, setting joints, physical parameters, and sensors.
Learning/evaluation design
Define tasks, observations, control inputs, and evaluation metrics. You can consult with us about selection of reinforcement learning/imitation learning, learning data, reward design, etc.
Migration/verification to robot
Check the differences in control cycle, sensor, and actuator characteristics. Evaluate the results using the robot and review the simulation conditions and controls.
Utilization of NVIDIA Isaac Sim/Isaac Lab
The software and learning methods to be used will be considered depending on the robot, purpose, and existing environment.
- Isaac Sim
- A platform used for robot/work environment simulation, sensor evaluation, and synthetic data generation.
- Isaac Lab
- A framework for robot learning based on Isaac Sim. Used for building environments such as reinforcement learning and imitation learning.
- Error adjustment with robot
- Consider domain randomization that changes conditions such as friction, mass, and delay, and parameter adjustment based on actual measurements.
- Actual machine cooperation
- Check existing control interfaces such as ROS 2 and robot SDK and design a connection method.
Decide on goals and evaluation indicators, and start with small verifications.
After confirming the target work, robot, and current model data, we organize the verification goals and deliverables. We set evaluation indicators such as grasping success rate, stability of motion, and working time, and compare the results of the simulation and the robot.
Deliverables such as environment settings, learning code, and evaluation reports, as well as the scope of robot verification, will be agreed upon before the project begins. It is also possible to proceed with a PoC for one task.
Frequently asked questions about Sim2Real development support
What is Sim2Real?
This is a development method that transfers robot control learned and verified through simulation to an robot. Since friction, mass, sensor error, communication delay, etc. differ between the robot and the simulation, it is necessary to take these differences into consideration in design and evaluation.
What is the difference between Isaac Sim and Isaac Lab?
NVIDIA Isaac Sim is a simulation platform that handles robots, work environments, sensors, etc. Isaac Lab is a robot learning framework based on Isaac Sim, which is used to develop reinforcement learning, imitation learning, etc. Combine them according to your purpose.
Can I consult with you just about building a simulation environment?
yes. We also accept consultations focused on necessary processes, such as environment construction, adjustment of existing models, preparation of learning environments, evaluation of migration to robots, etc. Please let us know about your current environment and challenges.
Can we discuss verification using Unitree robots?
Please let us know the robot you are considering, such as G1, H2, Go2, etc., and the work you will be doing. We will check the availability of the model, SDK/control interface, and robot development specifications, and propose the scope of support. You can also inquire about robot rental.
What is the development cost and time?
It varies depending on the target robot, the presence or absence of model data, the difficulty of the work, and the scope of the robot evaluation. First, we organize the verification goals and evaluation indicators, and estimate the scope, cost, and period for each process.
Sim2Real/Isaac Sim development consultation
Please let us know the target robot, the work you want to accomplish, and your current development environment. You can consult with us even when requirements and technology selection have not been decided.
Consult about Sim2Real developmentTechnical data:NVIDIA Isaac Sim ↗ / NVIDIA Isaac Lab ↗