Comparison of robots that can be introducedNarrow down the robot you want to use based on the specifications.
Bipedal walking and wheel movement, size and payload, and the range that can be developed. You can compare the manufacturer's published specifications and AI/development environment of 6 models that you can consider introducing using the same items.
Consult about model selectionSpecification confirmation date:
Select the robot to compare
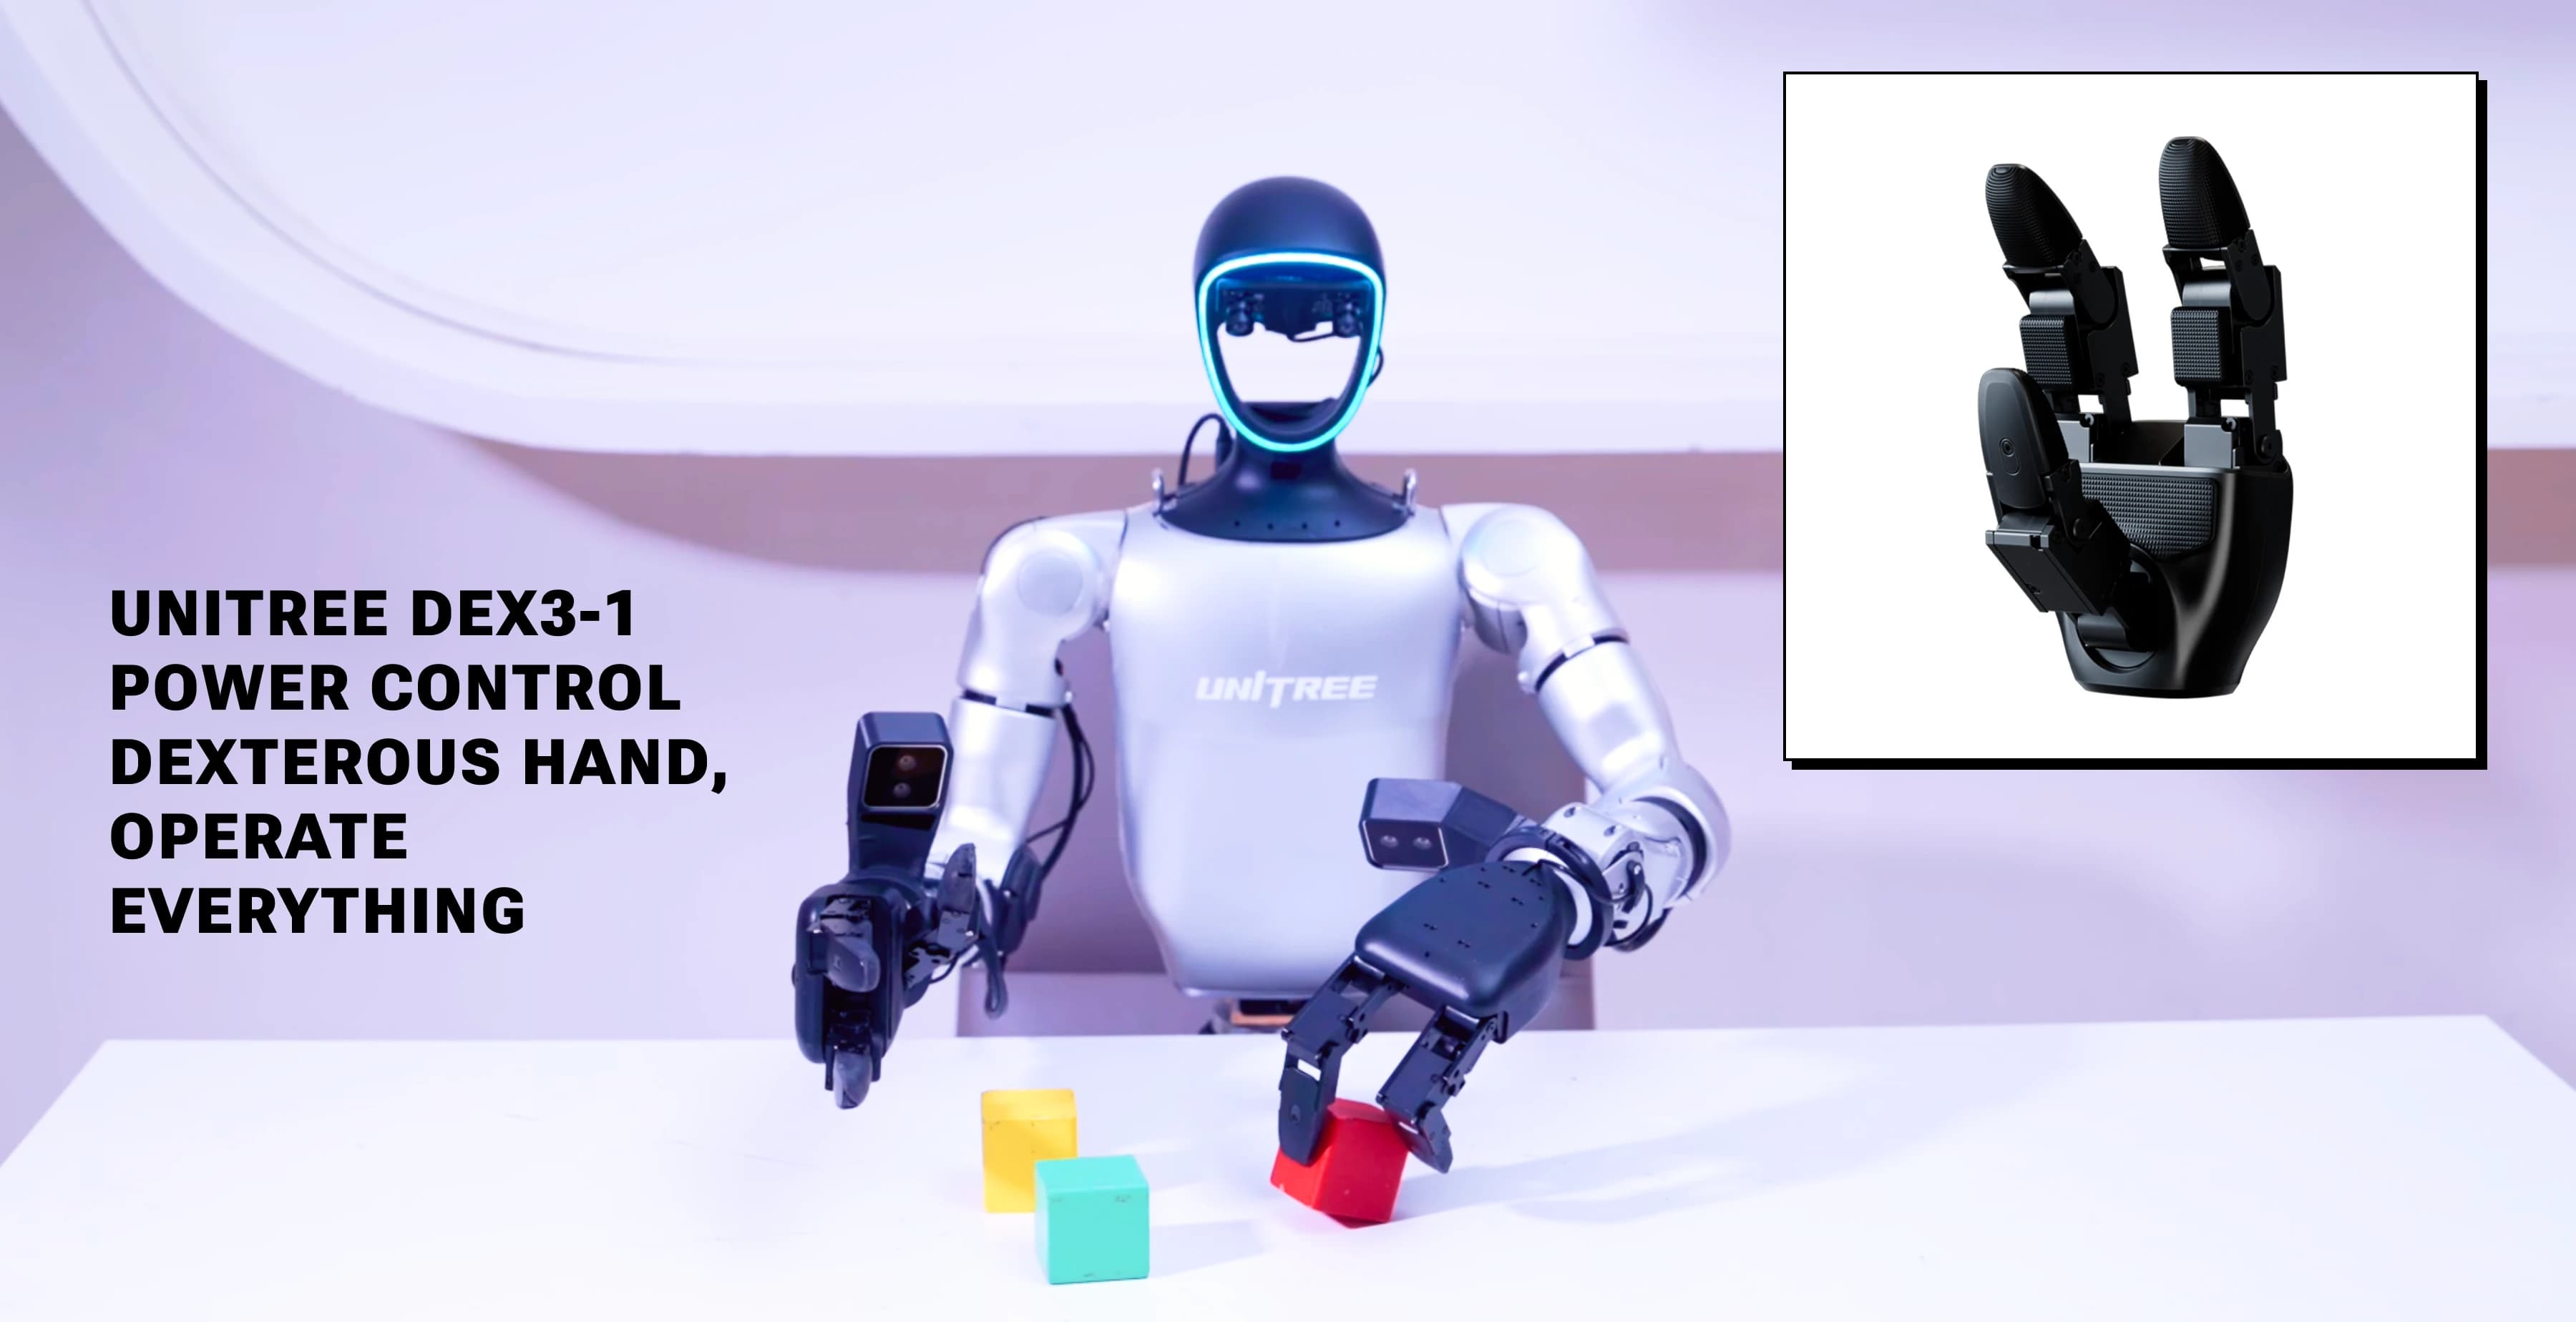
Unitree G1 / G1 EDU
A compact bipedal walking machine. For exhibition and research, we will choose between standard models and EDUs.
View robot details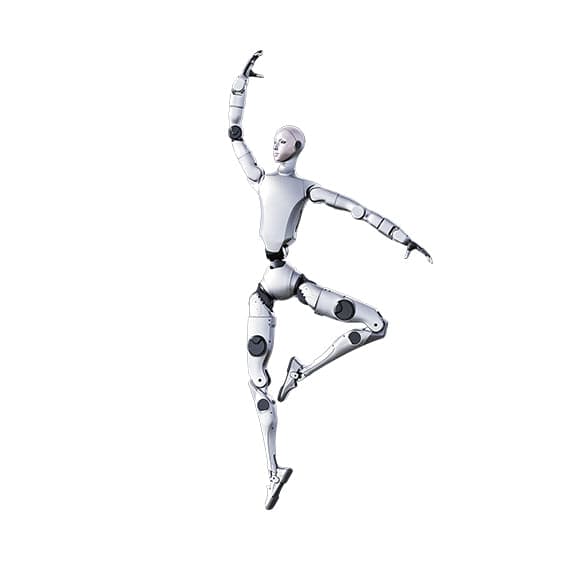
Unitree H2 / H2 EDU
A bipedal walking machine of approximately 1.8m. Check the delivery route and operating range based on the size and weight.
View robot details
ROBOTIS AI Worker
FFW-SG2 with a moving base and dual arms. It is a candidate for object manipulation and demonstration data collection.
View robot details
ROBOTIS AI Sapiens
K0 based on DYNAMIXEL Q. We will consider deploying whole body control and learning to actual machines.
View robot details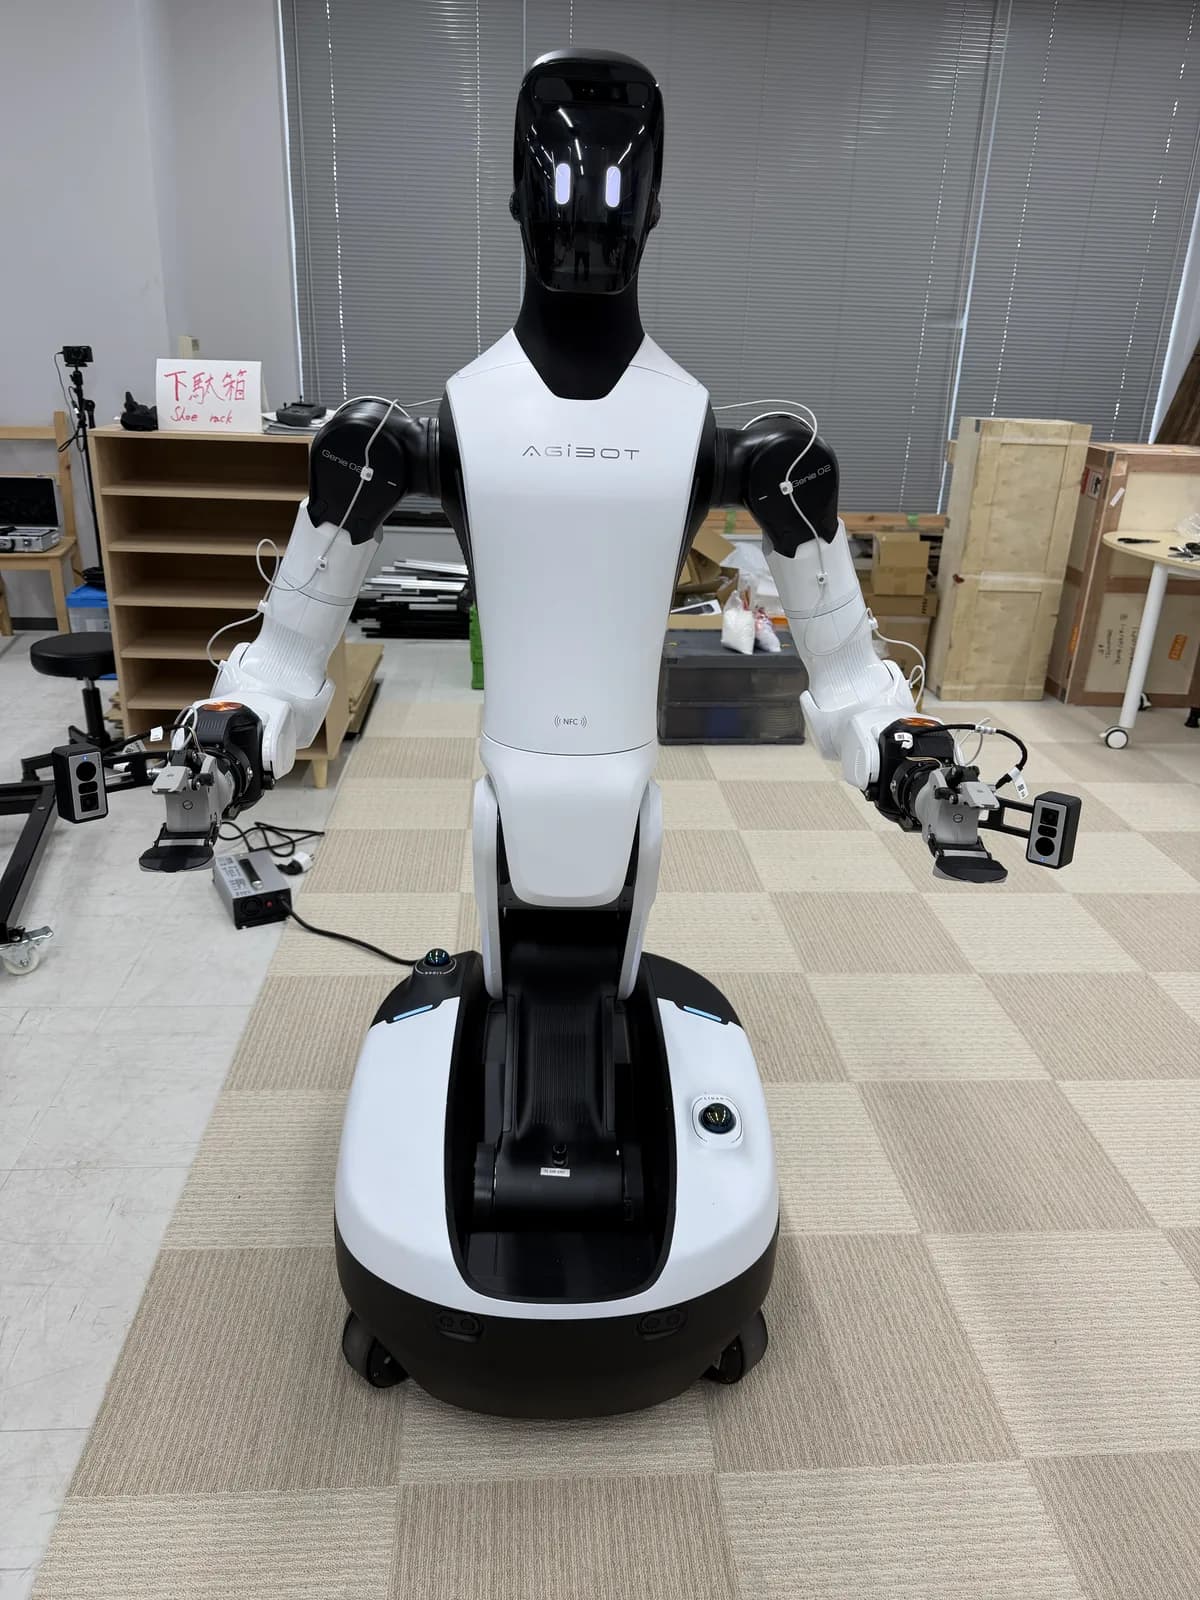
AgiBot G2
A machine with wheel movement and dual arms with 7 degrees of freedom. We will organize the target items and delivery/installation conditions.
View robot details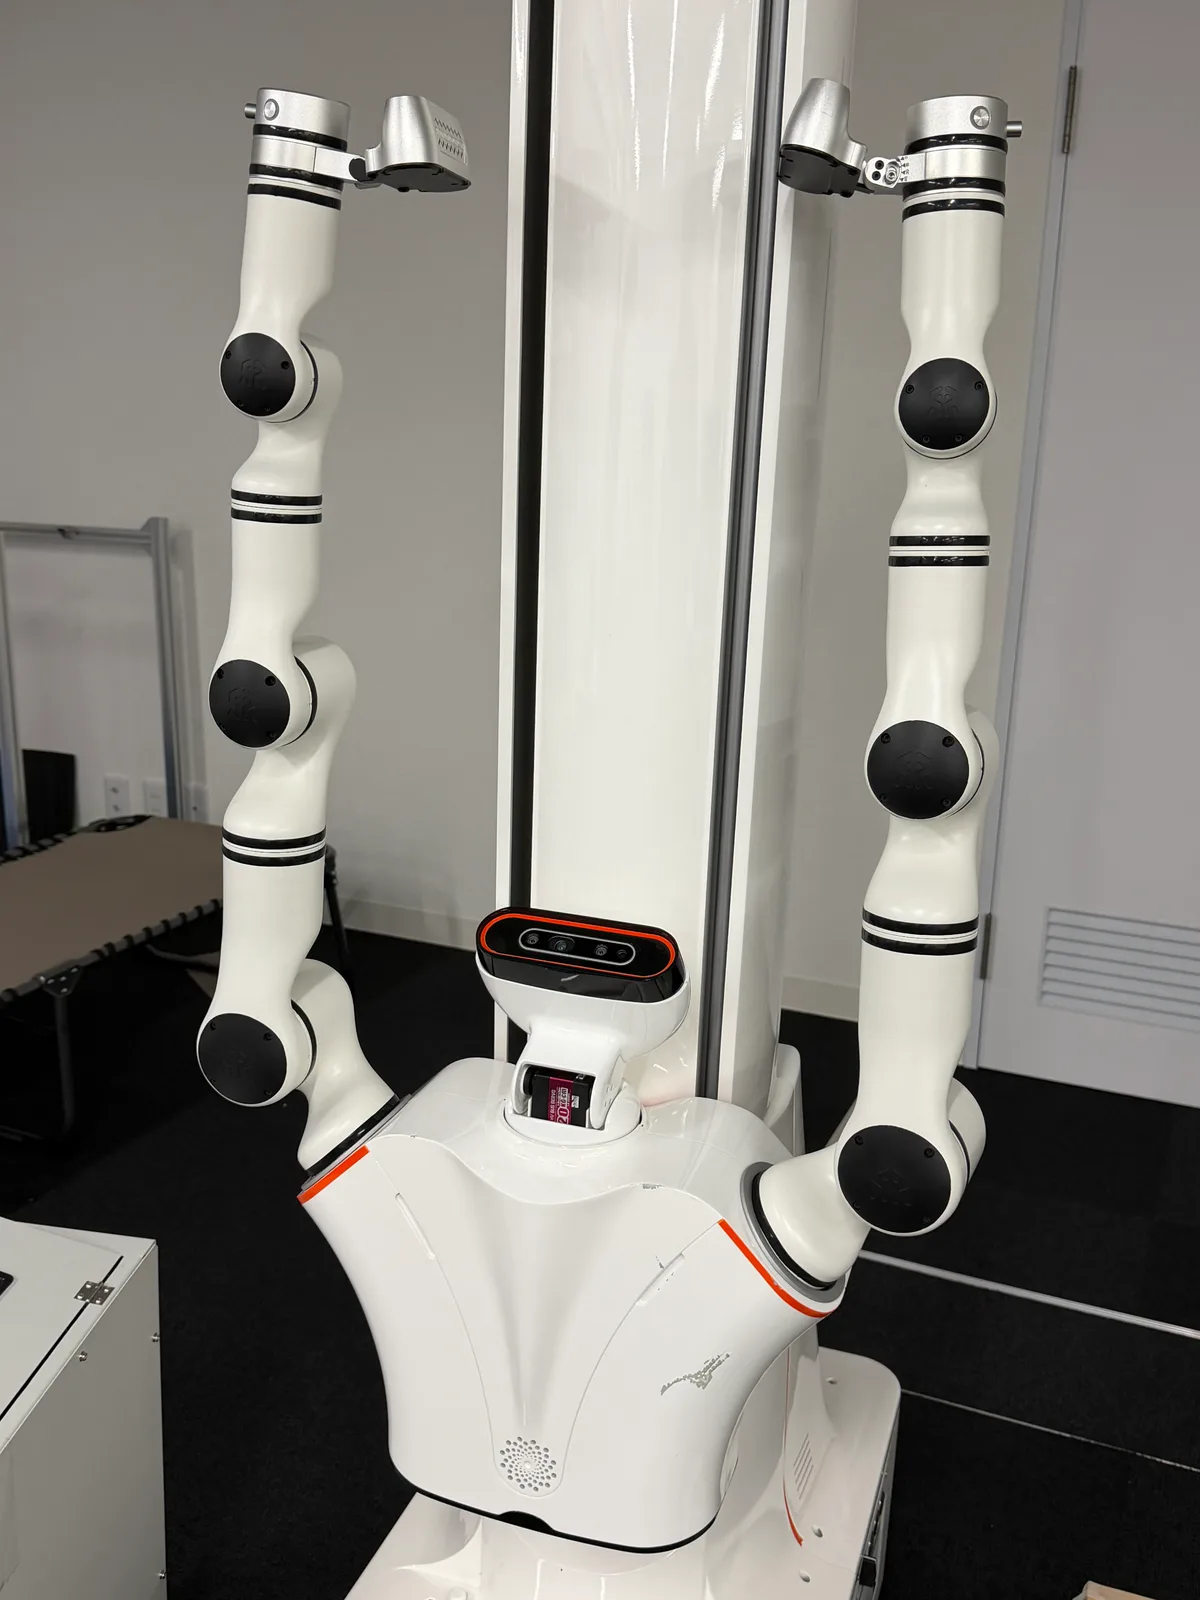
RealMan RMC-AIDAL
A mobile type with dual arms and a lifting mechanism. You can consider data collection and VLA implementation environments.
View robot detailsSpecification comparison table
You can narrow down the columns by unchecking the model. The table can be scrolled horizontally.
Number of robot being compared: 6
| Comparison items | UnitreeUnitree G1 / G1 EDU | UnitreeUnitree H2 / H2 EDU | ROBOTISROBOTIS AI Worker | ROBOTISROBOTIS AI Sapiens | AGIBOTAgiBot G2 | RealManRealMan RMC-AIDAL |
|---|---|---|---|---|---|---|
| robot configuration | bipedal type | bipedal type | Dual arm/wheel moving type (FFW-SG2) | Bipedal type (K0) | Dual arm/wheel moving type | Dual-arm/wheel-moving type (two-wheel configuration in instruction manual V1.1) |
| Dimensions (height x width x depth) | 1,320 × 450 × 200mm | 1,820 × 456 × 218mm | 1,623 × 604 × 602mm | Height 1,300mm (width and depth are not listed on the reference page) | 1,225〜1,795 × 640 × 760mm | When stored: 1,780 x 450 x 640mm / Shoulder width 545mm |
| weight | Standard: Approx. 35kg / EDU: Approx. 35kg or more (including battery) | Approximately 70kg (including battery) | 90kg | 34kg | 185kg | Approximately 157kg (instruction manual V1.1) |
| whole body degree of freedom | Standard: 23 / EDU: 23~43 (depending on configuration) | 31 | 25 (including moving mechanism) | 23 | 25 (Current official website table. There are differences depending on the version of the specifications) | The total body total is not listed in the reference materials. Individually check arms, head, lift, and trolley |
| freedom of one arm | 5 (Additional wrists/hands depend on configuration) | 7 | 7 | 5 | 7 | 6 (RM65-B-V. Varies depending on installed arm) |
| Arm load capacity | Maximum: Approx. 2kg / EDU: Approx. 3kg (varies depending on arm posture) | Rating: Approx. 7kg / Peak: Approx. 15kg (arm value in manufacturer's table) | Rating: 3kg for one arm, 6kg for double arms / Peak: 5kg for one arm, 10kg for double arms | Maximum 3kg (distinction between one arm and two arms is not listed on the reference page) | Rated 5kg (manufacturer's indicated value for one arm) | Arm rating: 5kg per arm / max. 1.4kg with attached 2-finger gripper (V1.1) |
| Power supply/operating time | 9,000mAh / approximately 2 hours (manufacturer's published value) | 15Ah・972Wh / about 3 hours (manufacturer's published value) | 25V・80Ah / 2,040Wh (manufacturer stated value) | 46.8V・9,000mAh (operating time is not listed on the reference page) | 2 units, total 1,652Wh / approximately 4 hours (manufacturer's published value) | Operating 3-4 hours (Instruction manual V1.1) |
| computing device | 8-core CPU/EDU can select additional computing modules | Intel Core i5/EDU added Core i7. High-performance computing module depends on configuration | NVIDIA Jetson AGX Orin 32GB | NVIDIA Jetson Orin NX 16GB | High-performance configuration: NVIDIA Jetson T5000 (do not directly compare FP4 values with TOPS of other machines) | NVIDIA Jetson AGX Orin 64GB |
| Main recognition sensor | Depth camera/3D LiDAR | Wide angle stereo camera | RGB-D camera x 3, LiDAR x 2, IMU | Check each provided configuration | 3D LiDAR x 2, stereo fisheye x 3, RGB-D on head and wrist | D435 depth camera, RGB camera, LiDAR, etc. (depending on configuration) |
| Development environment/secondary development | Secondary development is EDU. Check SDK, additional computing device, and hand configuration | Secondary development is EDU. Check additional calculation device/hand configuration | ROS 2, Python, C++, Web UI. Check the imitation learning environment by application. | Imitation learning, reinforcement learning, and simulation. Check public assets and control methods | Supports secondary development. Check the SDK, communication specifications, and provided configuration individually. | Official ROS code/URDF released. Check target arm, trolley, and OS |
| Purchase price announced by the manufacturer | Standard: US$13,500 / EDU: Contact manufacturer (excluding tax and shipping) | Standard: US$29,900 / EDU: Contact manufacturer (excluding tax and shipping) | There is no price listed on the official specification page referenced. | There is no price listed on the official specification page referenced. | There is no price listed on the official specification page referenced. | There is no price listed in the official materials referenced. |
| Consultation with EmplifAI | Consultation regarding rental, purchase, and operation development | Consultation on configuration for rental/research and development | Consultation regarding rental/purchase/data collection | Consultation regarding rental, purchase, and research and development | Consultation regarding purchase, installation, and technical verification | Consultation regarding purchase, rental, and development |
The manufacturer's published price is not the total price for domestic installation. Costs including tax, shipping, currency exchange, configuration, development, installation, and operating costs will be estimated individually. Operating time and payload are not measured values under the same conditions.
Compare VLA/learning environments
We distinguish between manufacturer's correspondence tables, public codes, and research institute implementation examples. Even if a model name is listed, it does not guarantee that it will work with all robot configurations.
| Comparison items | UnitreeUnitree G1 / G1 EDU | UnitreeUnitree H2 / H2 EDU | ROBOTISROBOTIS AI Worker | ROBOTISROBOTIS AI Sapiens | AGIBOTAgiBot G2 | RealManRealMan RMC-AIDAL |
|---|---|---|---|---|---|---|
| VLA/robot base model | Policy support for π0.5/GR00T for manufacturer official LeRobot cooperation. Check target configuration of G1 and hand | VLA implementation on H2/H2 EDU is independently verified. Distinct from H2 Plus' GR00T configuration | Official Cyclo Intelligence: Inference backend for SmolVLA, XVLA, π0, π0.5, GR00T N1.7 | The specific VLA/trained model for K0 cannot be confirmed in the reference materials. Individual verification | Manufacturer Genie Studio introduces π0, OpenVLA, GR00T, etc. Target configuration of G2 robot is confirmed individually | UCLA public implementation example: SmolVLA・π0-FAST・π0.5. Distinguished from manufacturer standard compliance |
| Imitation learning/reinforcement learning | Official LeRobot learning/actual inference example, RL Gym G1 reinforcement learning example | Individually check learning models, scope of control, and published assets | Official: ACT・Diffusion. From demonstration collection to data conversion, learning, and inference | K0 official product materials guide imitation learning and reinforcement learning. Check execution environment | Guide to Genie RL in product documentation. Check the scope of learning/inference provided | UCLA public implementation examples: ACT, Diffusion, VQ-BeT. Demonstration collection and LeRobot cooperation |
| Simulation/Sim2Real | Official Isaac Lab G1 operating environment, MuJoCo execution example | Check the target H2 model and environment availability | Official: Isaac Lab・MuJoCo・URDF. Check the robot model and version | Official GitHub is Sim2Real/MuJoCo for K1. Application to K0 requires confirmation | Official Genie Sim released. Check target robot assets and G2 configuration | Manufacturer's official URDF model. Confirm that the research model, trolley, and arm configuration match. |
| ROS 2/SDK cooperation | Official ROS 2 SDK2. A configuration compatible with secondary development is required. | H2 control example for official ROS 2/SDK2. Secondary development is EDU | Official AI Worker ROS 2 package released | Official ai_sapiens is ROS 2 for K1. Compatibility with K0 in the comparison table has not been confirmed. | Genie Sim is compatible with ROS 2. Conditions for providing the G2 actual SDK are confirmed individually. | Manufacturer's official ROS code, UCLA's ROS 2 Foxy implementation example. Environment construction and robot verification required |
GitHub public code/development materials
When selecting a model, please also check compatible machines, branches, dependent environments, and licenses. Manufacturer formulas and research institute implementation examples are posted separately.
Unitree G1 / G1 EDU
Examples of G1 data conversion, LeRobot learning, and robot inference
Isaac Lab operating environment for G1. Distribution model is for simulation verification
Example of G1 reinforcement learning/MuJoCo/robot deployment
Unitree H2 / H2 EDU
Example of H2's DDS communication, arm, and whole body control
ROBOTIS AI Worker
Data collection/LeRobot collaboration/VLA inference
ROBOTIS AI Sapiens
The current README is for K1. K0 compatibility is not guaranteed
Including K1 learning environment. The scope of disclosure for K0 will be confirmed individually.
AgiBot G2
Simulation, data collection, and evaluation. This is not a complete G2 control set.
RealMan RMC-AIDAL
Instruction manual, URDF, ROS code in RMC-AIDA-L branch
RealMan AIDA data collection, imitation learning, VLA learning and inference. Verification with robot configuration
Supplementary specifications and official sources
Unitree G1 / G1 EDU
The price of the standard G1 cannot be treated as the price of the G1 EDU that supports secondary development. The degrees of freedom including the hand and the calculation device vary depending on the configuration.
Unitree G1
Unitree H2 / H2 EDU
This column is a comparison of H2/H2 EDU. Please check the specifications separately from the H2 Plus/H2-D specifications. The payload capacity varies depending on posture and operating conditions.
Image: Unitree Robotics
ROBOTIS AI Worker
The specifications are different from the fixed type FFW-BG2. Peak payload capacity varies depending on posture and movement. The power consumption is not the calculated value of 25V x 80Ah, but the value listed by the manufacturer.
Image: ROBOTIS (Apache License 2.0)
ROBOTIS AI Sapiens
Manufacturers are announcing possible changes in specifications and gradual release of development assets. Check the disclosure status of the necessary assets and the configuration of the provided robot individually.
Image: ROBOTIS (Apache License 2.0)
AgiBot G2
The current official website has a total of 25 degrees of freedom and the chassis has 3 degrees of freedom, and the 2025 specification referenced by our robot introduction page has a total of 26 degrees of freedom and the chassis has 4 degrees of freedom. We will confirm the version and configuration of the target robot at the time of quotation.
AgiBot G2 delivered to EmplifAI office (July 2026, in-house photo)
RealMan RMC-AIDAL
The notation RMC-AIDA-L is also used in official documents. The table refers to the instruction manual V1.1 for the two-wheel configuration. Specifications will vary depending on the four-wheel configuration, different arms, and grippers. The weight an arm can carry and the weight it can actually grip are not the same.
RealMan RMC-AIDAL robot
After the numbers, check.
Actions you want to delegate
Does it require bipedal walking or full-body movement, or can it be done with two arms on a moving base? Before deciding on the shape of the robot, decide on the target work and success conditions.
Scope of development and operation
Access to SDK, hand and camera configuration, learning environment, operating staff. Just because the compatibility is indicated in the specification table does not necessarily mean that the desired function can be used.
Total cost for implementation
Compare the robot cost plus transportation, installation, development, and operation. Availability of sales/rental, delivery date, and scope of domestic support will be confirmed individually.