
Factory/substation 3D digital twin x four-legged inspection robot integrated introduction supportFirst, we create 3D spatial data of the site in millimeter units, and design and demonstrate inspection patrols using a quadrupedal robot on that map.
This is an integrated package that provides one-stop high-speed 3D digital twin construction using EmplifAI's handy 3D scanner "XGRIDS Lixel K2" and autonomous patrol/equipment inspection PoC using the quadruped walking robot "Unitree Go2" + thermal PTZ camera for factories, substations, plants, and logistics/infrastructure facilities. We eliminate failures such as ``When the robot was brought to the site, it was unable to pass through a step or narrow passage'' or ``the angle of view of the camera could not reach the instrument'' by performing a 3D spatial diagnosis of 10 million points in advance.
Consult about support for integrated implementation of 3D digital twin x four-legged inspection robot in factories/substations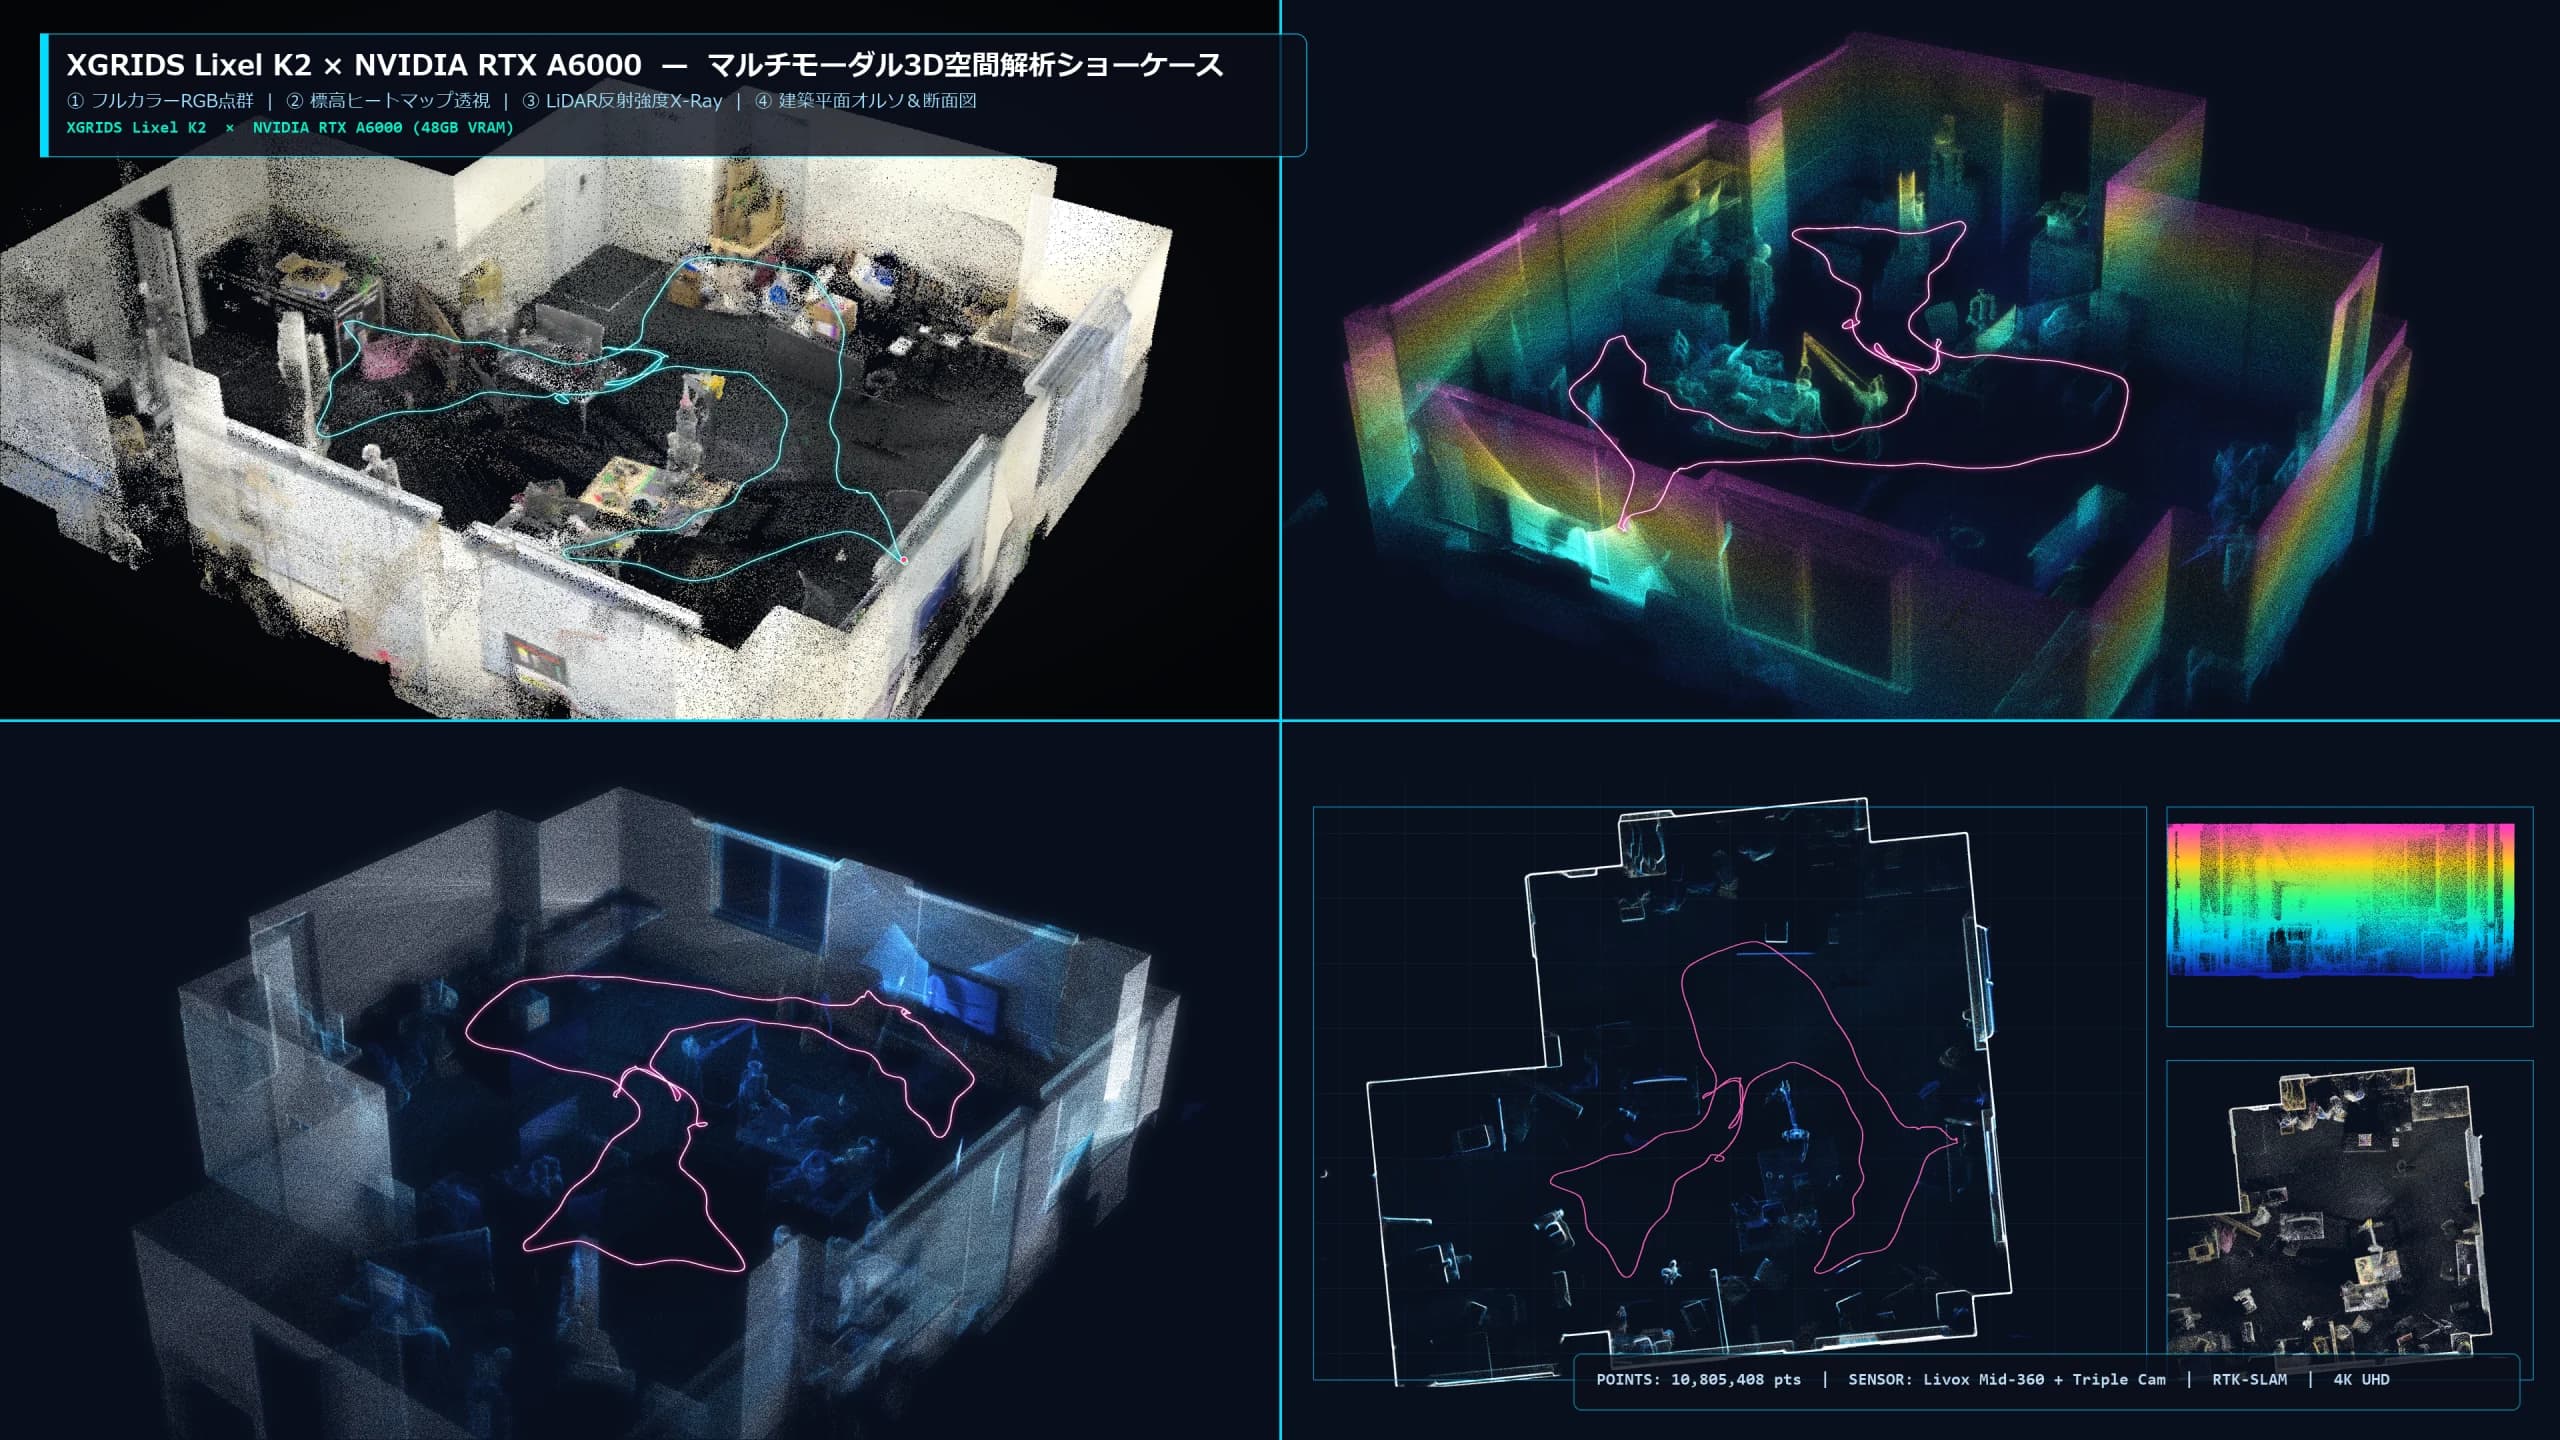
3D digital twin with 10.8 million measured points that can be moved 360° on the browser
This is actual data measured while walking in EmplifAI's robot development lab (Unitree G1 humanoid/double-arm robot installation environment) for just 89 seconds using our own XGRIDS Lixel K2. In addition to being able to rotate and zoom 360° by dragging or swiping the mouse, you can experience switching between four display modes, ceiling slicing (cross-sectional cutting), and viewpoint jump to the robot installation spot on the spot.
What can be done with XGRIDS 3D spatial data × physical AI?
The greatest value of 3D scanning a site is not just in creating drawings for human viewing. By combining millimeter-level 3D spatial data with EmplifAI's humanoid robots (Unitree G1, etc.), dual-arm manipulators (OpenArm), VLA models, and the NVIDIA Isaac Sim environment, everything from pre-diagnosis for robot introduction to virtual training, autonomous movement, and remote control will change dramatically.
Digitize real space in 89 seconds and create a virtual verification environment where humanoid and dual-arm robots move
Even in factories, warehouses, and research facilities where drawings do not exist, you can obtain 3D point clouds and live-action textures of the entire room by simply walking around with XGRIDS Lixel K2. In the actual measurement data of the EmplifAI lab, the entire space (68.3 m2, 10.8 million points), including the humanoid by the window (Unitree G1) and the dual-arm robot work cell in the center, was converted into spatial data in just 89 seconds. By importing the acquired space into the NVIDIA Isaac Sim or ROS 2 environment, you can run simulations (Real2Sim2Real) of walking routes, whole body control, and grasping motions before bringing the robot to the site.
What can be achieved with this combination
- Build a full-scale 3D virtual space where humanoids and AMRs run and work by simply walking around the site.
- Collision detection model and navigation map conversion cooperation for NVIDIA Isaac Sim, USD, and ROS 2
- Environment generation for robot reinforcement learning and imitation learning that directly reflects on-site fixtures, workbenches, and obstacles
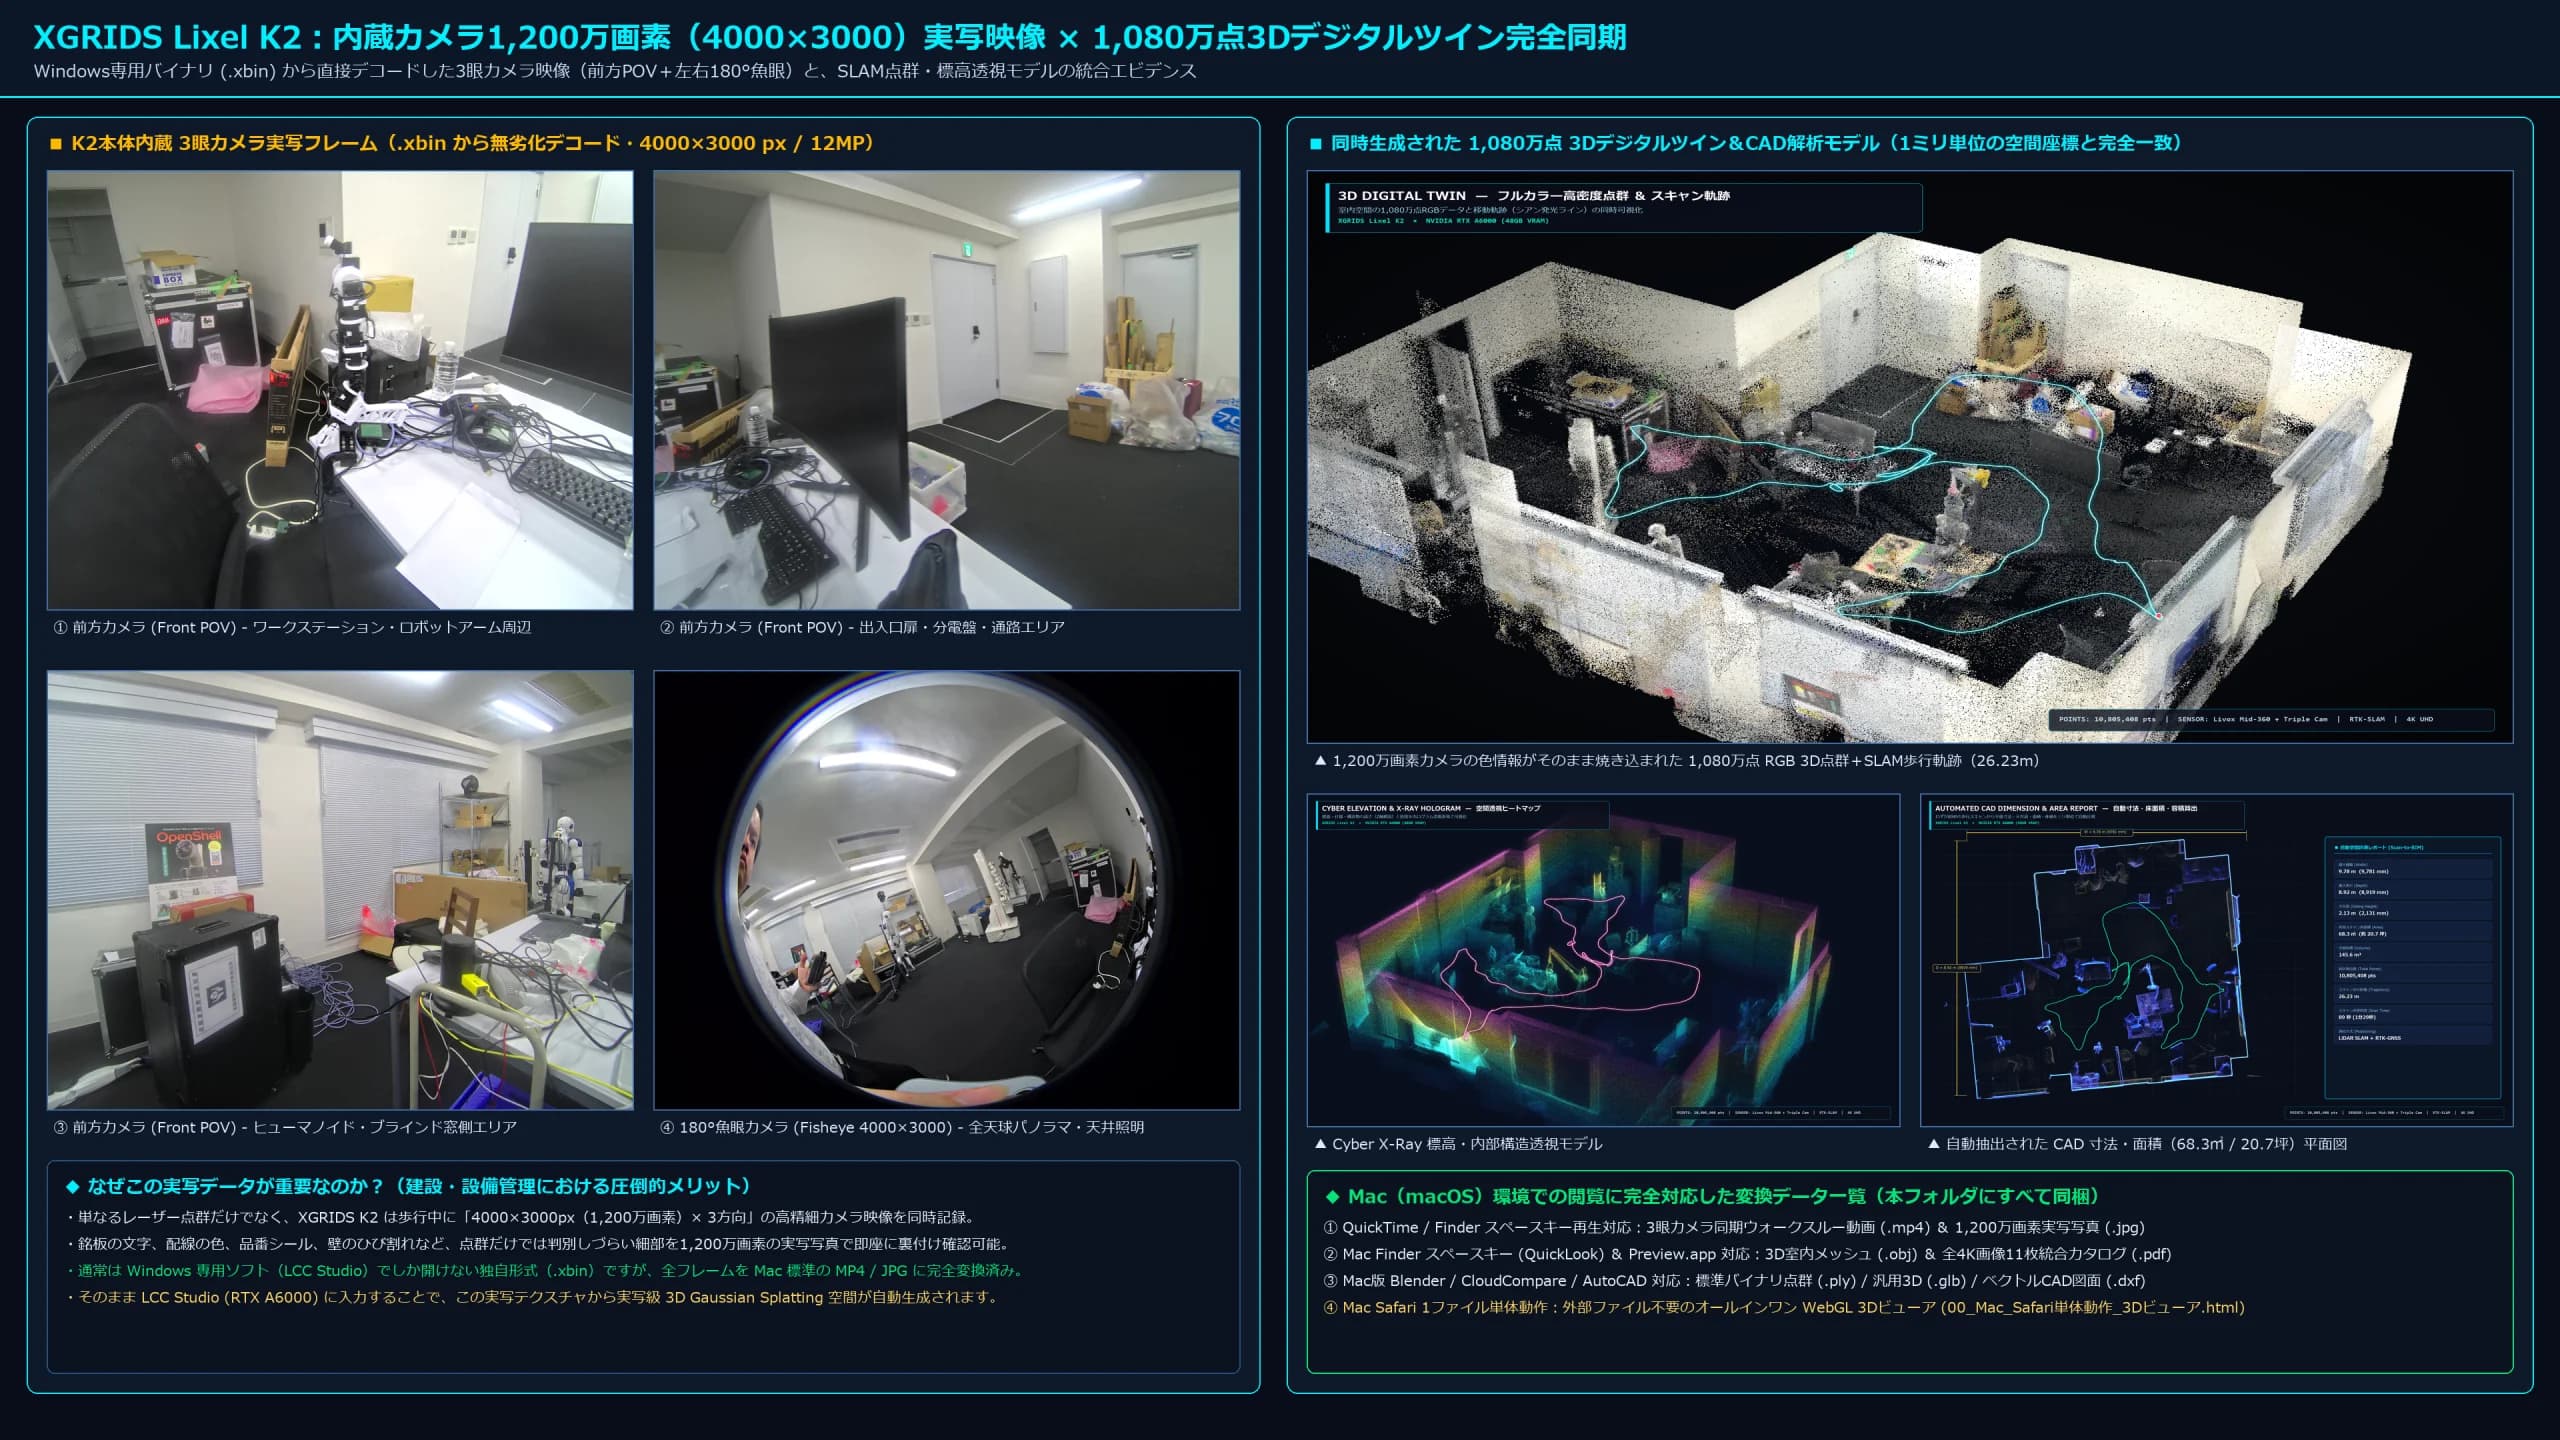
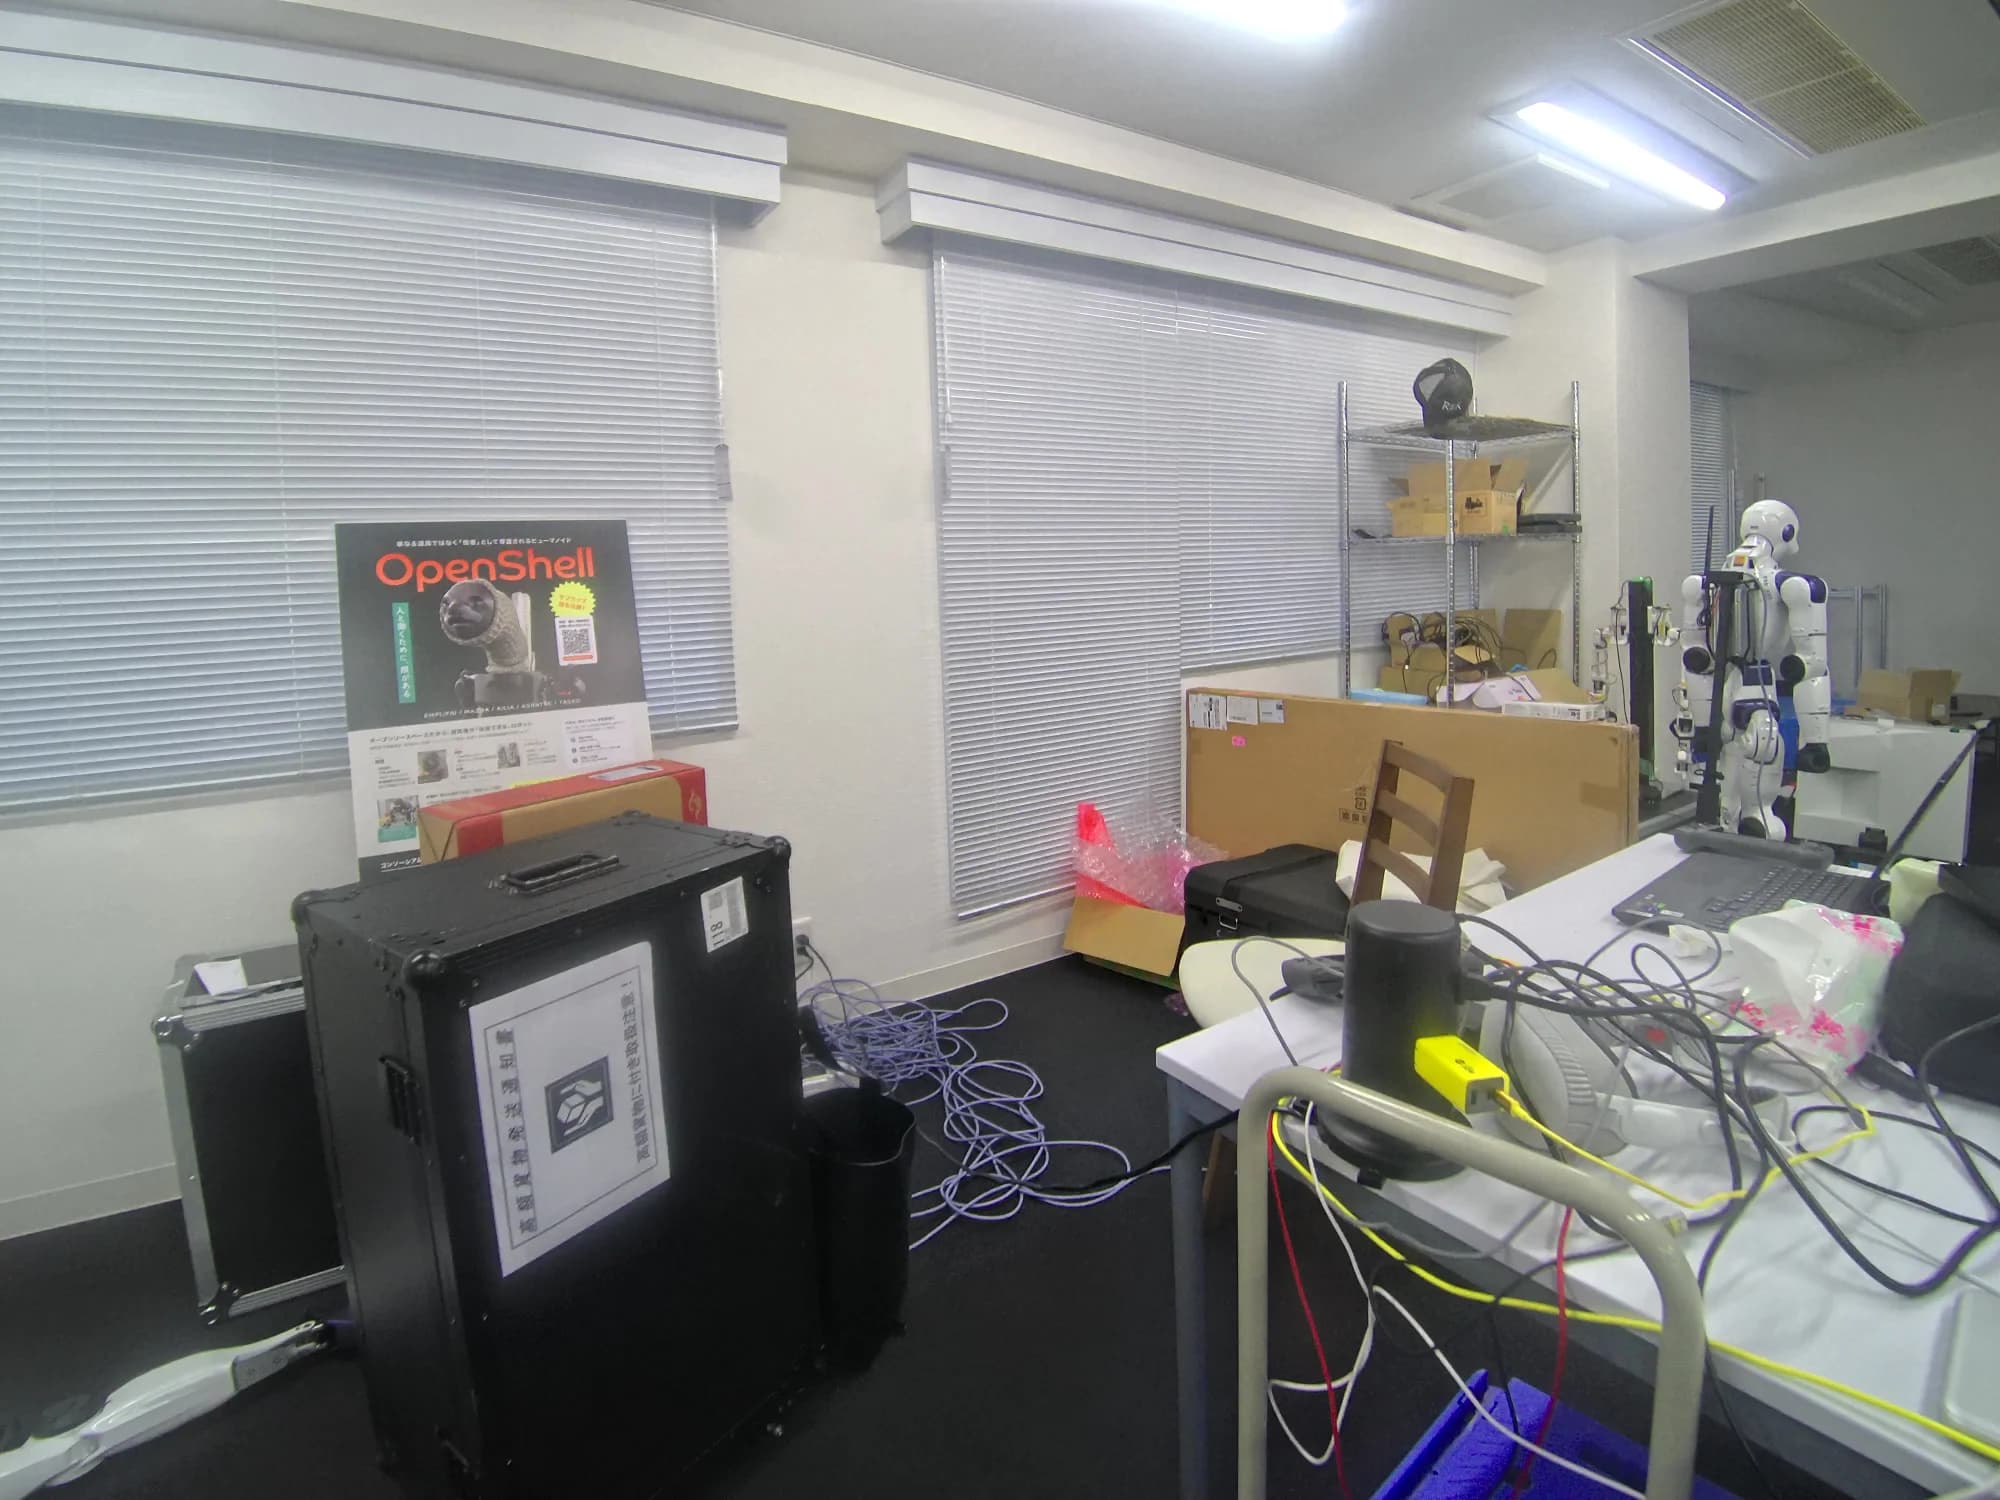
Watch the video: From an 89-second walkthrough to the creation of a 3D space with 10.8 million points
You can switch between the 360° multimodal analysis video of the lab space actually measured with XGRIDS Lixel K2 and the 10.8 million-point spatial build-up video created by laser scanning.
360° rotation × 3 modes continuous change (Full color RGB → Cyber elevation → LiDAR X-Ray)
This is a showcase video that rotates 10.8 million points of 3D spatial data generated from a single walking scan (89 seconds) and displays it in 360° rotation while seamlessly switching between three modes: live-action full color RGB, cyber elevation hologram by height, and X-Ray perspective based on laser reflection intensity.
"4K spatial analysis/drawing/inspection visualization" that can be developed from multiple angles from a single scan
From the acquired high-density 3D data to full-color point clouds, elevation holograms, 1m grid architectural ortho diagrams, CAD floor plans with automatic dimensions, millimeter heat maps of floor unevenness and wall verticality, and robot delivery clearance verification, you can develop analysis views that suit your purpose. Click on the thumbnail to switch, and click on the image to enlarge in high resolution.
Click to enlarge 4K high-definition image4-division multimodal 3D spatial analysis showcase
From one scan data, four modes can be simultaneously developed: (1) full-color RGB point cloud, (2) elevation heat map perspective, (3) 1m grid architectural orthoplan, and (4) cross-sectional profile. You can understand the appearance, dimensions, and structure of the space at a glance.
We have an actual XGRIDS Lixel K2 and provide comprehensive support from 3D spatial measurement to physical AI collaboration.
EmplifAI has installed an actual XGRIDS handheld 3D scanner "Lixel K2" and a workstation GPU "NVIDIA RTX A6000" with a large capacity VRAM of 48GB in its own laboratory. We can create a 3D digital twin of the entire room (68.3 m2, 10.8 million points) in just 89 seconds of walking, and provide comprehensive consultation on everything from point clouds, CAD/BIM drawings, and floor unevenness inspections to 3D Gaussian Splatting (3DGS) and humanoid and dual-arm robot simulation (NVIDIA Isaac Sim/Real2Sim) collaboration.
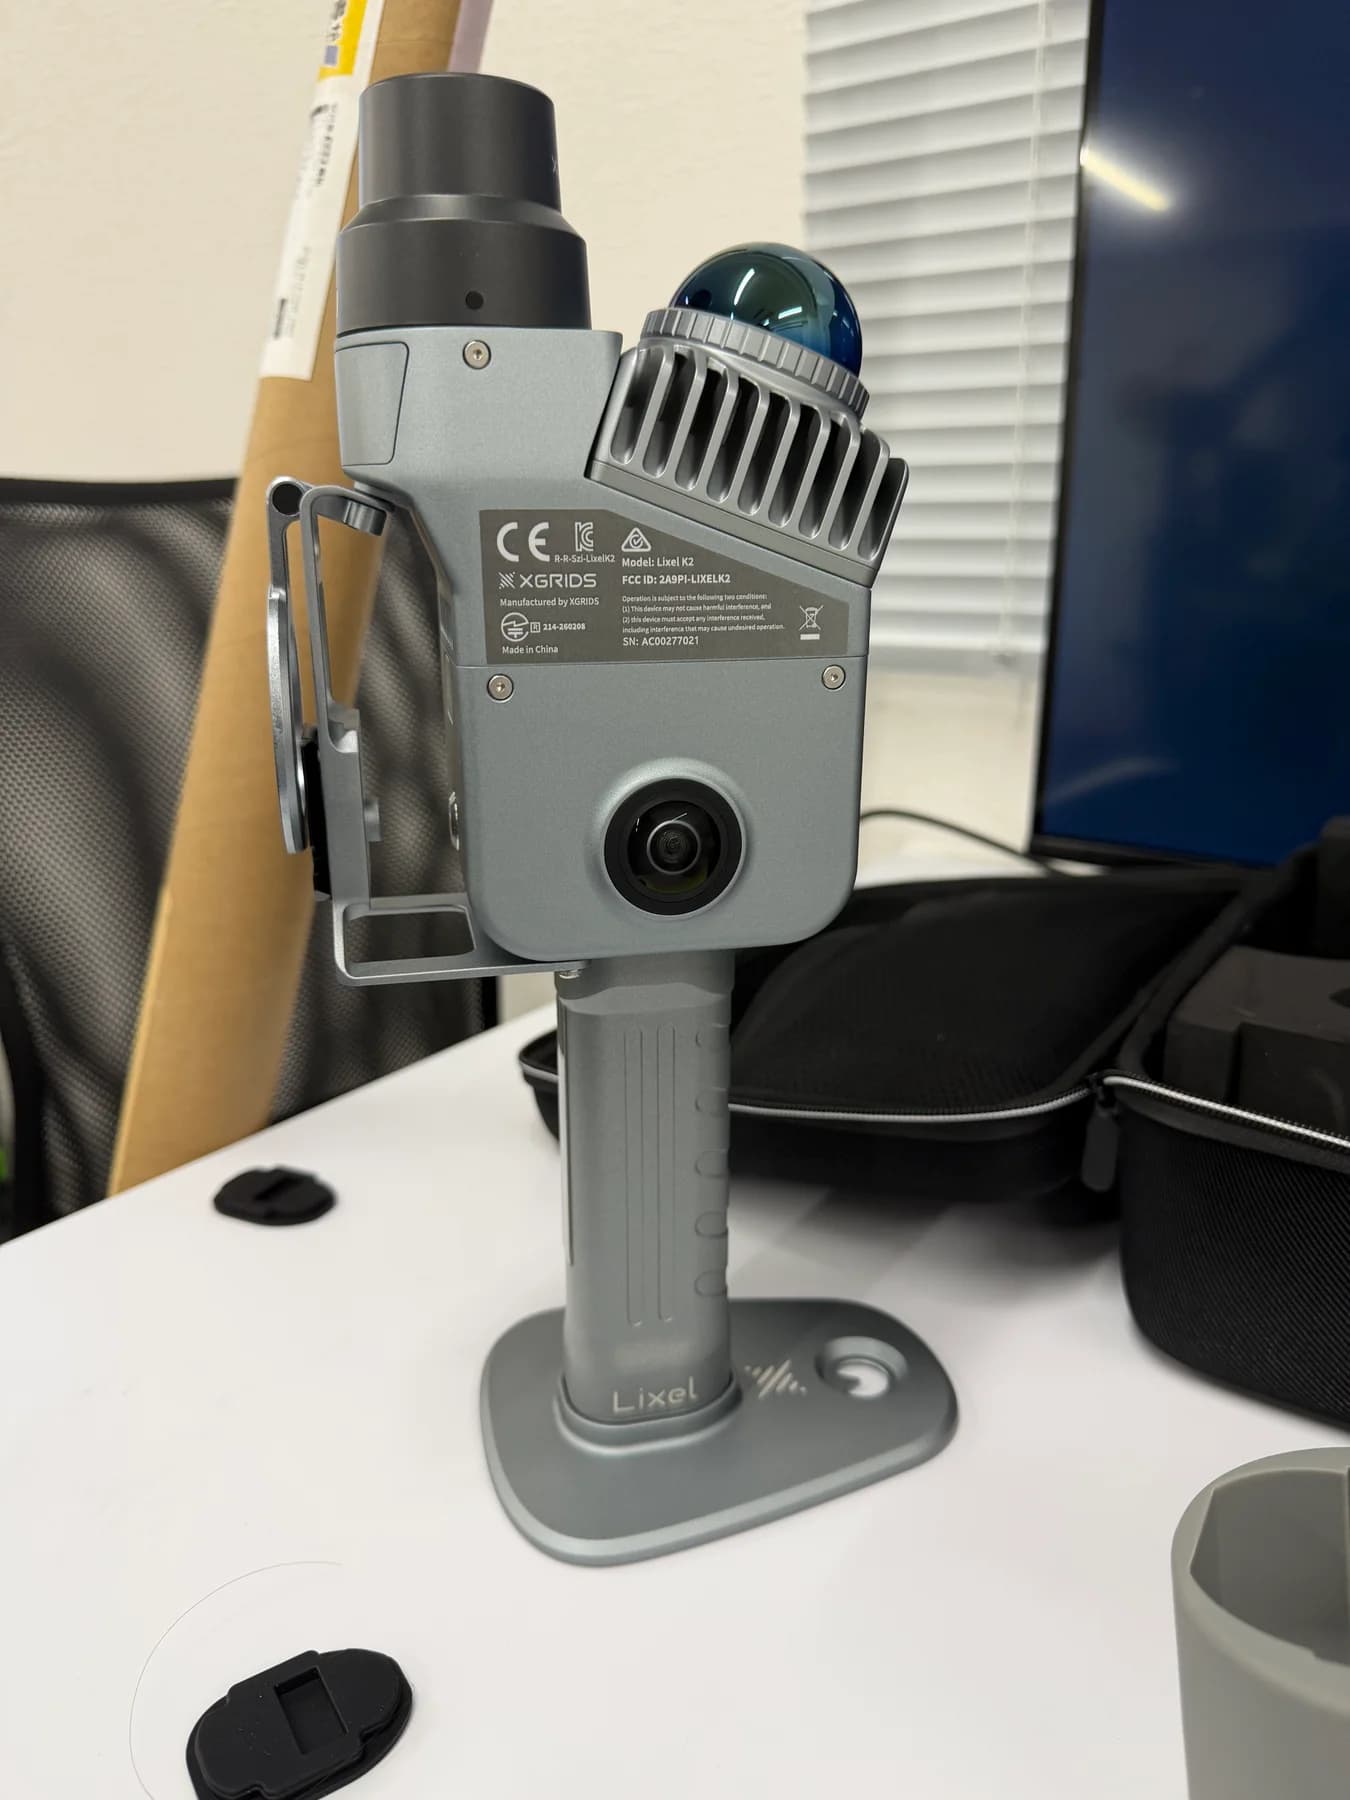
K2's 3D digital twin, robot, and physical AI collaboration
XGRIDS Lixel K2 special showcase page
We will introduce you to an interactive 3D viewer with 10.8 million points, 4K spatial analysis, physical AI collaboration, on-site measurement and rental consultation.
Consultation content and deliverables
- STEP 1: On-site 3D measurement
- Walking scan the target area with XGRIDS Lixel K2 and generate high-density 3D point cloud, 360° live action, and 3DGS
- STEP 2: Space/flow line diagnosis
- Analyze floor unevenness (unevenness/sloping), passage width clearance, and visible position of inspection targets (instruments and switchboards) in 3D
- STEP 3: Robot inspection PoC
- Introducing Unitree Go2 + visible light 4K/thermal PTZ camera, etc., and on-site verification of patrol driving and thermal imaging/instrument photography
- STEP 4: Digital ledger collaboration
- Link acquired inspection images and temperature logs with coordinates on a 3D spatial map and connect to remote confirmation and maintenance plans.
- Deliverables
- 3D point cloud/CAD plane/cross section/unevenness/interference diagnosis report, Go2 field tour PoC result report/inspection data
- price
- Individual estimates based on target area, number of inspection points, camera configuration used, and number of on-site verification days
How we work
We will ask you about the current situation, target robot, site conditions, and desired timing, and then we will begin work after agreeing on the scope of implementation and preconditions. Deliverables and prices will be specified in the individual quotation.
An all-in-one model of “3D spatial measurement x four-legged inspection SI” that neither surveying companies nor robot trading companies can do.
Even in aging plants and factories without drawings, you can create a patrol map in just a few minutes of walking.
Even in facilities that have been repeatedly expanded and renovated and do not have the latest drawings, you can obtain over 10 million 3D point clouds and live-action panoramas just by walking around with Lixel K2. We create robot maps that accurately reflect piping overhangs and temporary equipment.
"Camera blind spot & shooting distance simulation" in 3D space
Using the acquired 3D digital twin, we will quantitatively determine whether the overhead meters and switchboards can be seen from the Go2's height (approximately 40 to 60 cm) and whether a small thermal (ZT6) is sufficient or whether a 30x optical zoom (ZT30) is required before the robot is installed.
Floor surface unevenness diagnosis in millimeter units and ROS 2 autonomous driving/direct connection to Isaac Sim
After identifying areas at risk of falls and slips for quadrupedal walkers using a heat map of uneven floor surfaces, we convert it into an occupancy grid map for ROS 2 (Nav2) or an NVIDIA Isaac Sim virtual environment. We realize a safe and on-site PoC without rework.
Frequently asked questions
What can I request for 3D digital twin x four-legged inspection robot integrated introduction support for factories and substations?
This is an integrated package that provides one-stop high-speed 3D digital twin construction using EmplifAI's handy 3D scanner "XGRIDS Lixel K2" and autonomous patrol/equipment inspection PoC using the quadruped walking robot "Unitree Go2" + thermal PTZ camera for factories, substations, plants, and logistics/infrastructure facilities. We eliminate failures such as ``When the robot was brought to the site, it was unable to pass through a step or narrow passage'' or ``the angle of view of the camera could not reach the instrument'' by performing a 3D spatial diagnosis of 10 million points in advance. The specific scope of work will be confirmed and agreed upon before starting work, including robot, site, and desired deliverables.
How are the costs and scope of delivery for support for the integrated introduction of 3D digital twin x four-legged inspection robots at factories and substations determined?
We will confirm the target robot, number of machines, implementation location, and required deliverables, and provide an individual estimate of availability, scope of work, completion conditions, and cost.
Is it possible to first request only STEP 1, ``3D scan/robot introduction feasibility diagnosis'', and then proceed to robot PoC after checking the results?
Yes, this is the most recommended way to proceed. First, we deliver a 3D point cloud, CAD floor plan, uneven floor surface, and aisle clearance diagnosis report through a one-day walk-through scan of the site, and once the route that the robot can reliably take and the necessary camera specifications are clear, we proceed to STEP 3, the robot inspection PoC.
Consultation on support for integrated implementation of 3D digital twin x four-legged inspection robot in factories and substations
Please let us know the target robot, location, issue you would like to solve, and desired timing. We will inform you about the implementation details and estimate.
Consult about support for integrated implementation of 3D digital twin x four-legged inspection robot in factories/substations