
3D Gaussian Splatting (3DGS) Remote factory inspection/digital on-site observation constructionFrom on-site walking scans that take just a few minutes, to a remote inspection/attendance environment where you can walk through a 3D space just like a photo in your browser.
High-speed on-site measurement using the handy 3D scanner "XGRIDS Lixel K2" (360° LiDAR + 12 million pixels x 3-lens panoramic camera) and 3D Gaussian using the workstation GPU "NVIDIA RTX A6000 (VRAM 48GB)" This is a service that combines Splatting (3DGS) processing to archive and remotely share factories, plants, construction sites, and research facilities as realistic 3D spaces. Light reflections, glass, detailed pipe labels, and floor textures that are difficult to express with conventional point clouds are reproduced in real-life quality, and dimensional measurement data in millimeter units is also provided.
Consult about 3D Gaussian Splatting (3DGS) remote factory inspection/digital on-site construction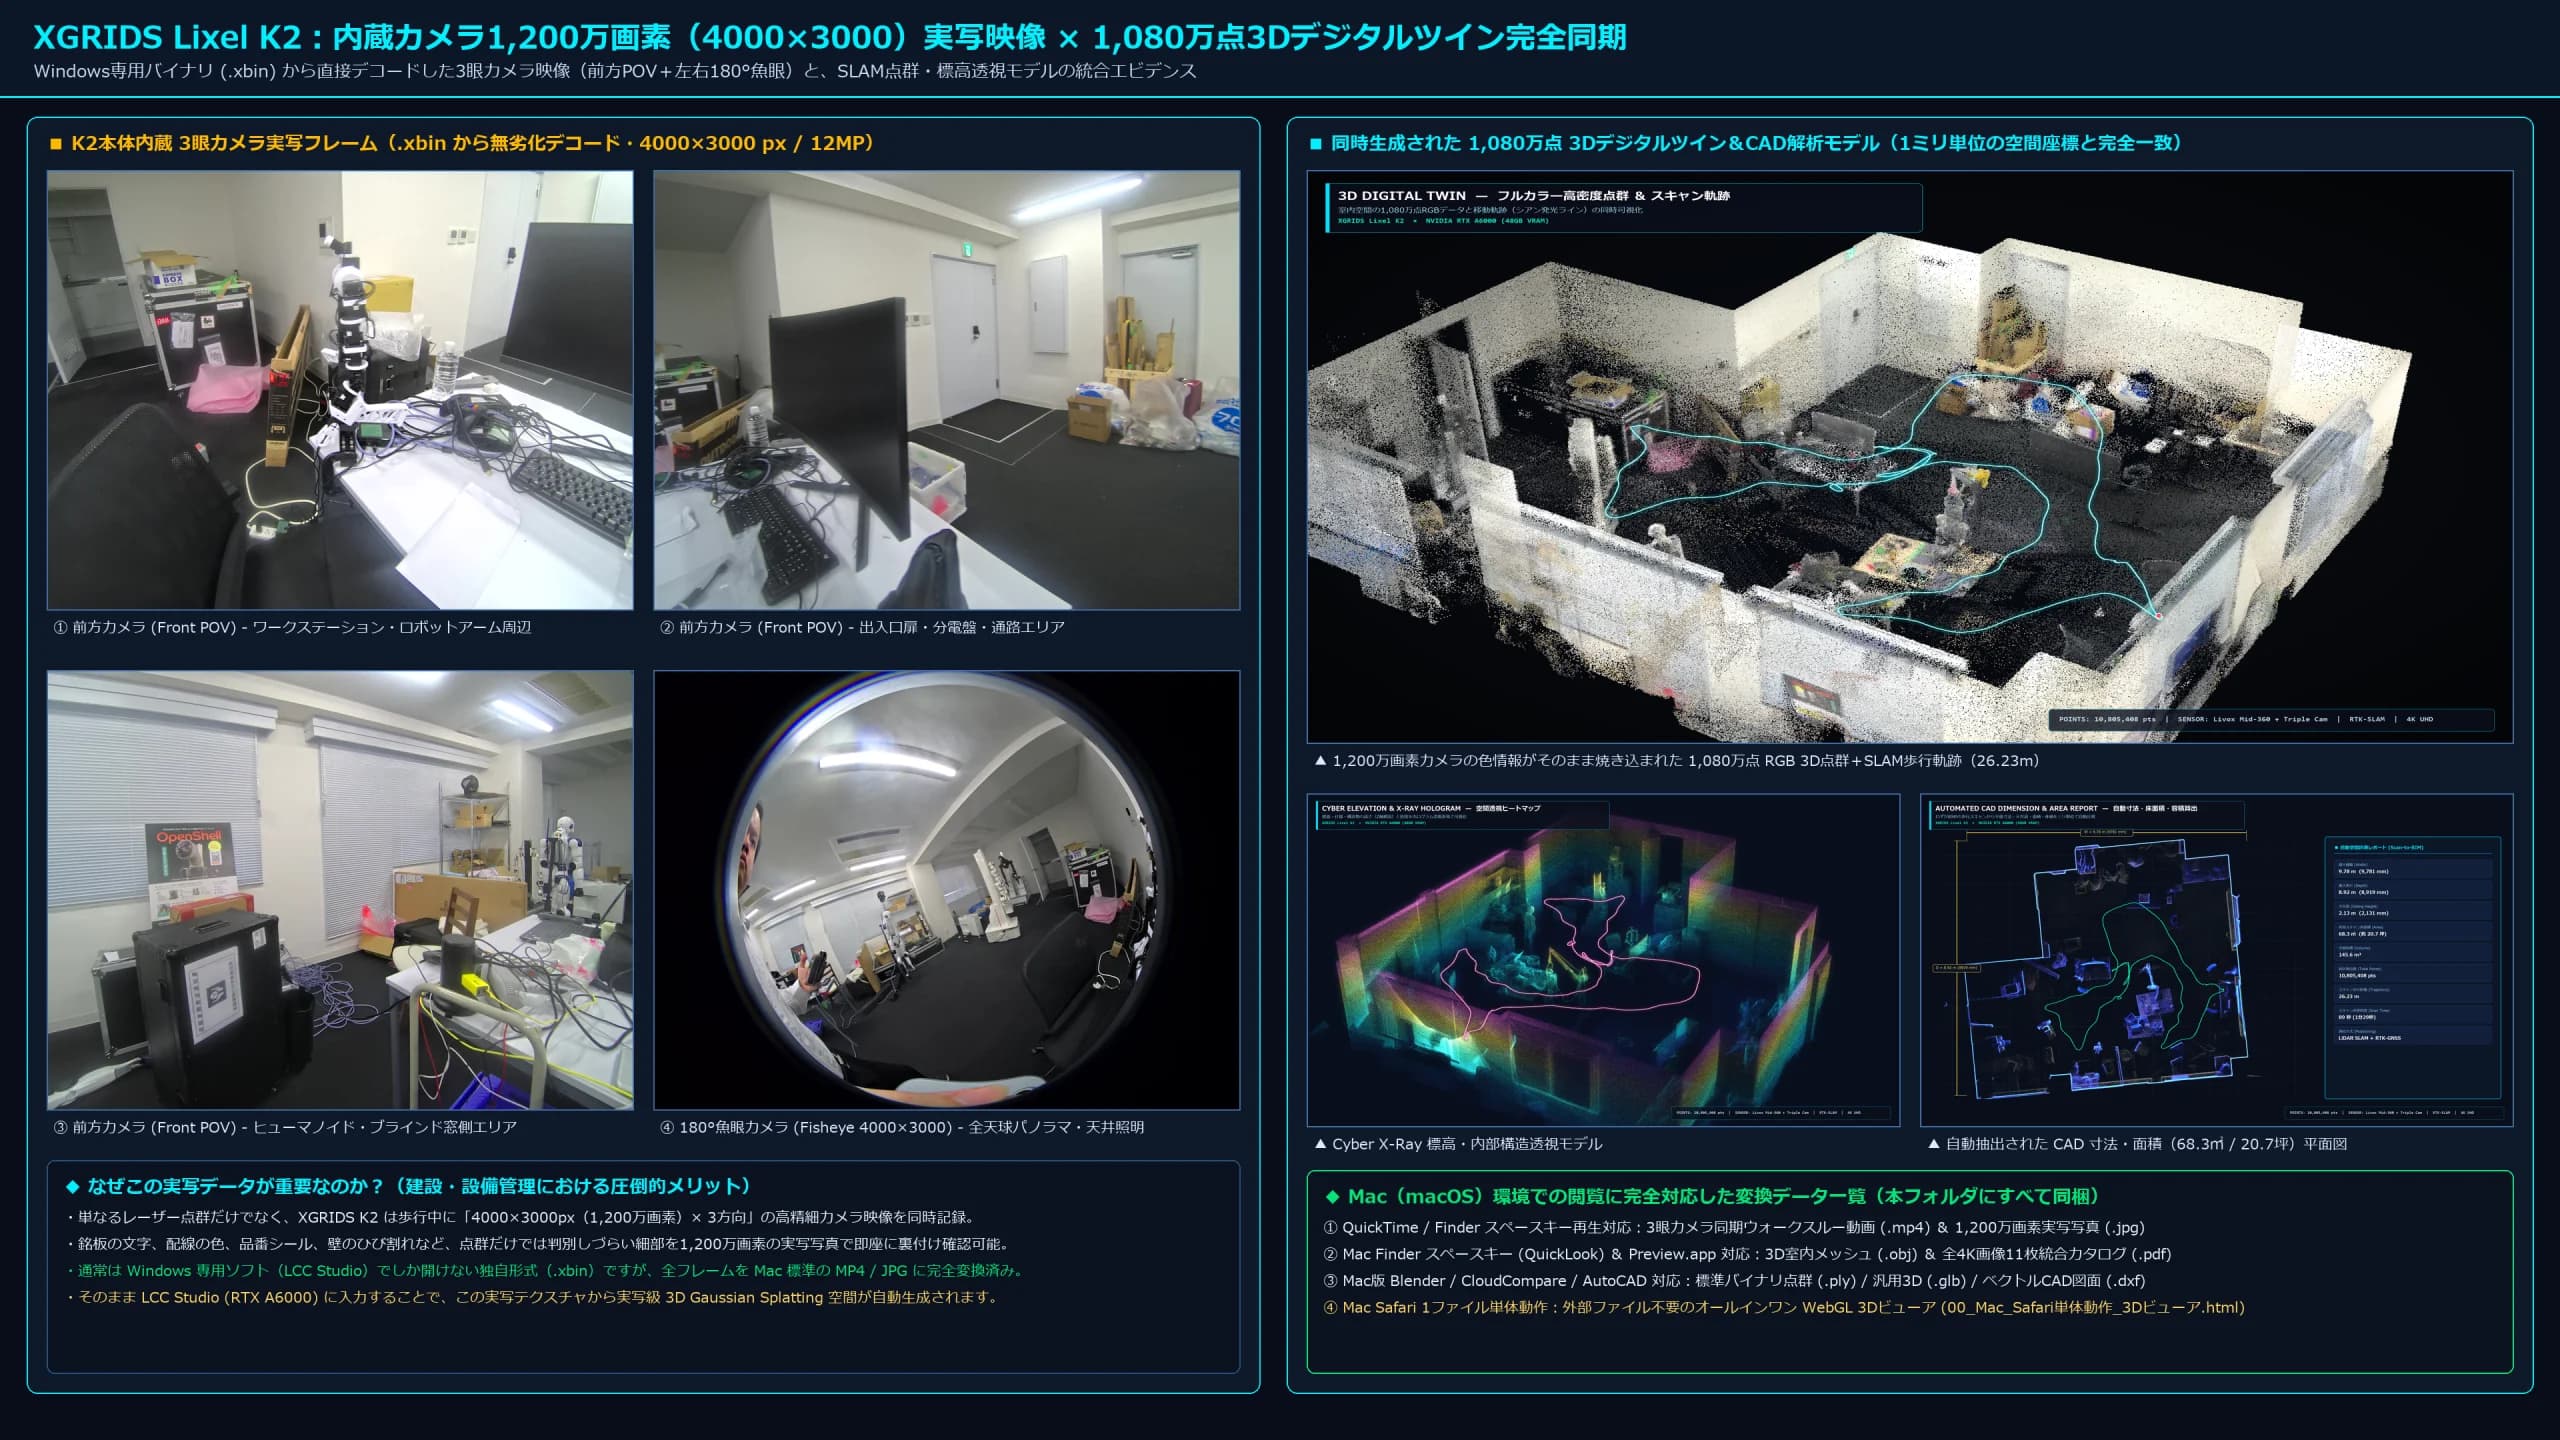
3D digital twin with 10.8 million measured points that can be moved 360° on the browser
This is actual data measured while walking in EmplifAI's robot development lab (Unitree G1 humanoid/double-arm robot installation environment) for just 89 seconds using our own XGRIDS Lixel K2. In addition to being able to rotate and zoom 360° by dragging or swiping the mouse, you can experience switching between four display modes, ceiling slicing (cross-sectional cutting), and viewpoint jump to the robot installation spot on the spot.
What can be done with XGRIDS 3D spatial data × physical AI?
The greatest value of 3D scanning a site is not just in creating drawings for human viewing. By combining millimeter-level 3D spatial data with EmplifAI's humanoid robots (Unitree G1, etc.), dual-arm manipulators (OpenArm), VLA models, and the NVIDIA Isaac Sim environment, everything from pre-diagnosis for robot introduction to virtual training, autonomous movement, and remote control will change dramatically.
Digitize real space in 89 seconds and create a virtual verification environment where humanoid and dual-arm robots move
Even in factories, warehouses, and research facilities where drawings do not exist, you can obtain 3D point clouds and live-action textures of the entire room by simply walking around with XGRIDS Lixel K2. In the actual measurement data of the EmplifAI lab, the entire space (68.3 m2, 10.8 million points), including the humanoid by the window (Unitree G1) and the dual-arm robot work cell in the center, was converted into spatial data in just 89 seconds. By importing the acquired space into the NVIDIA Isaac Sim or ROS 2 environment, you can run simulations (Real2Sim2Real) of walking routes, whole body control, and grasping motions before bringing the robot to the site.
What can be achieved with this combination
- Build a full-scale 3D virtual space where humanoids and AMRs run and work by simply walking around the site.
- Collision detection model and navigation map conversion cooperation for NVIDIA Isaac Sim, USD, and ROS 2
- Environment generation for robot reinforcement learning and imitation learning that directly reflects on-site fixtures, workbenches, and obstacles
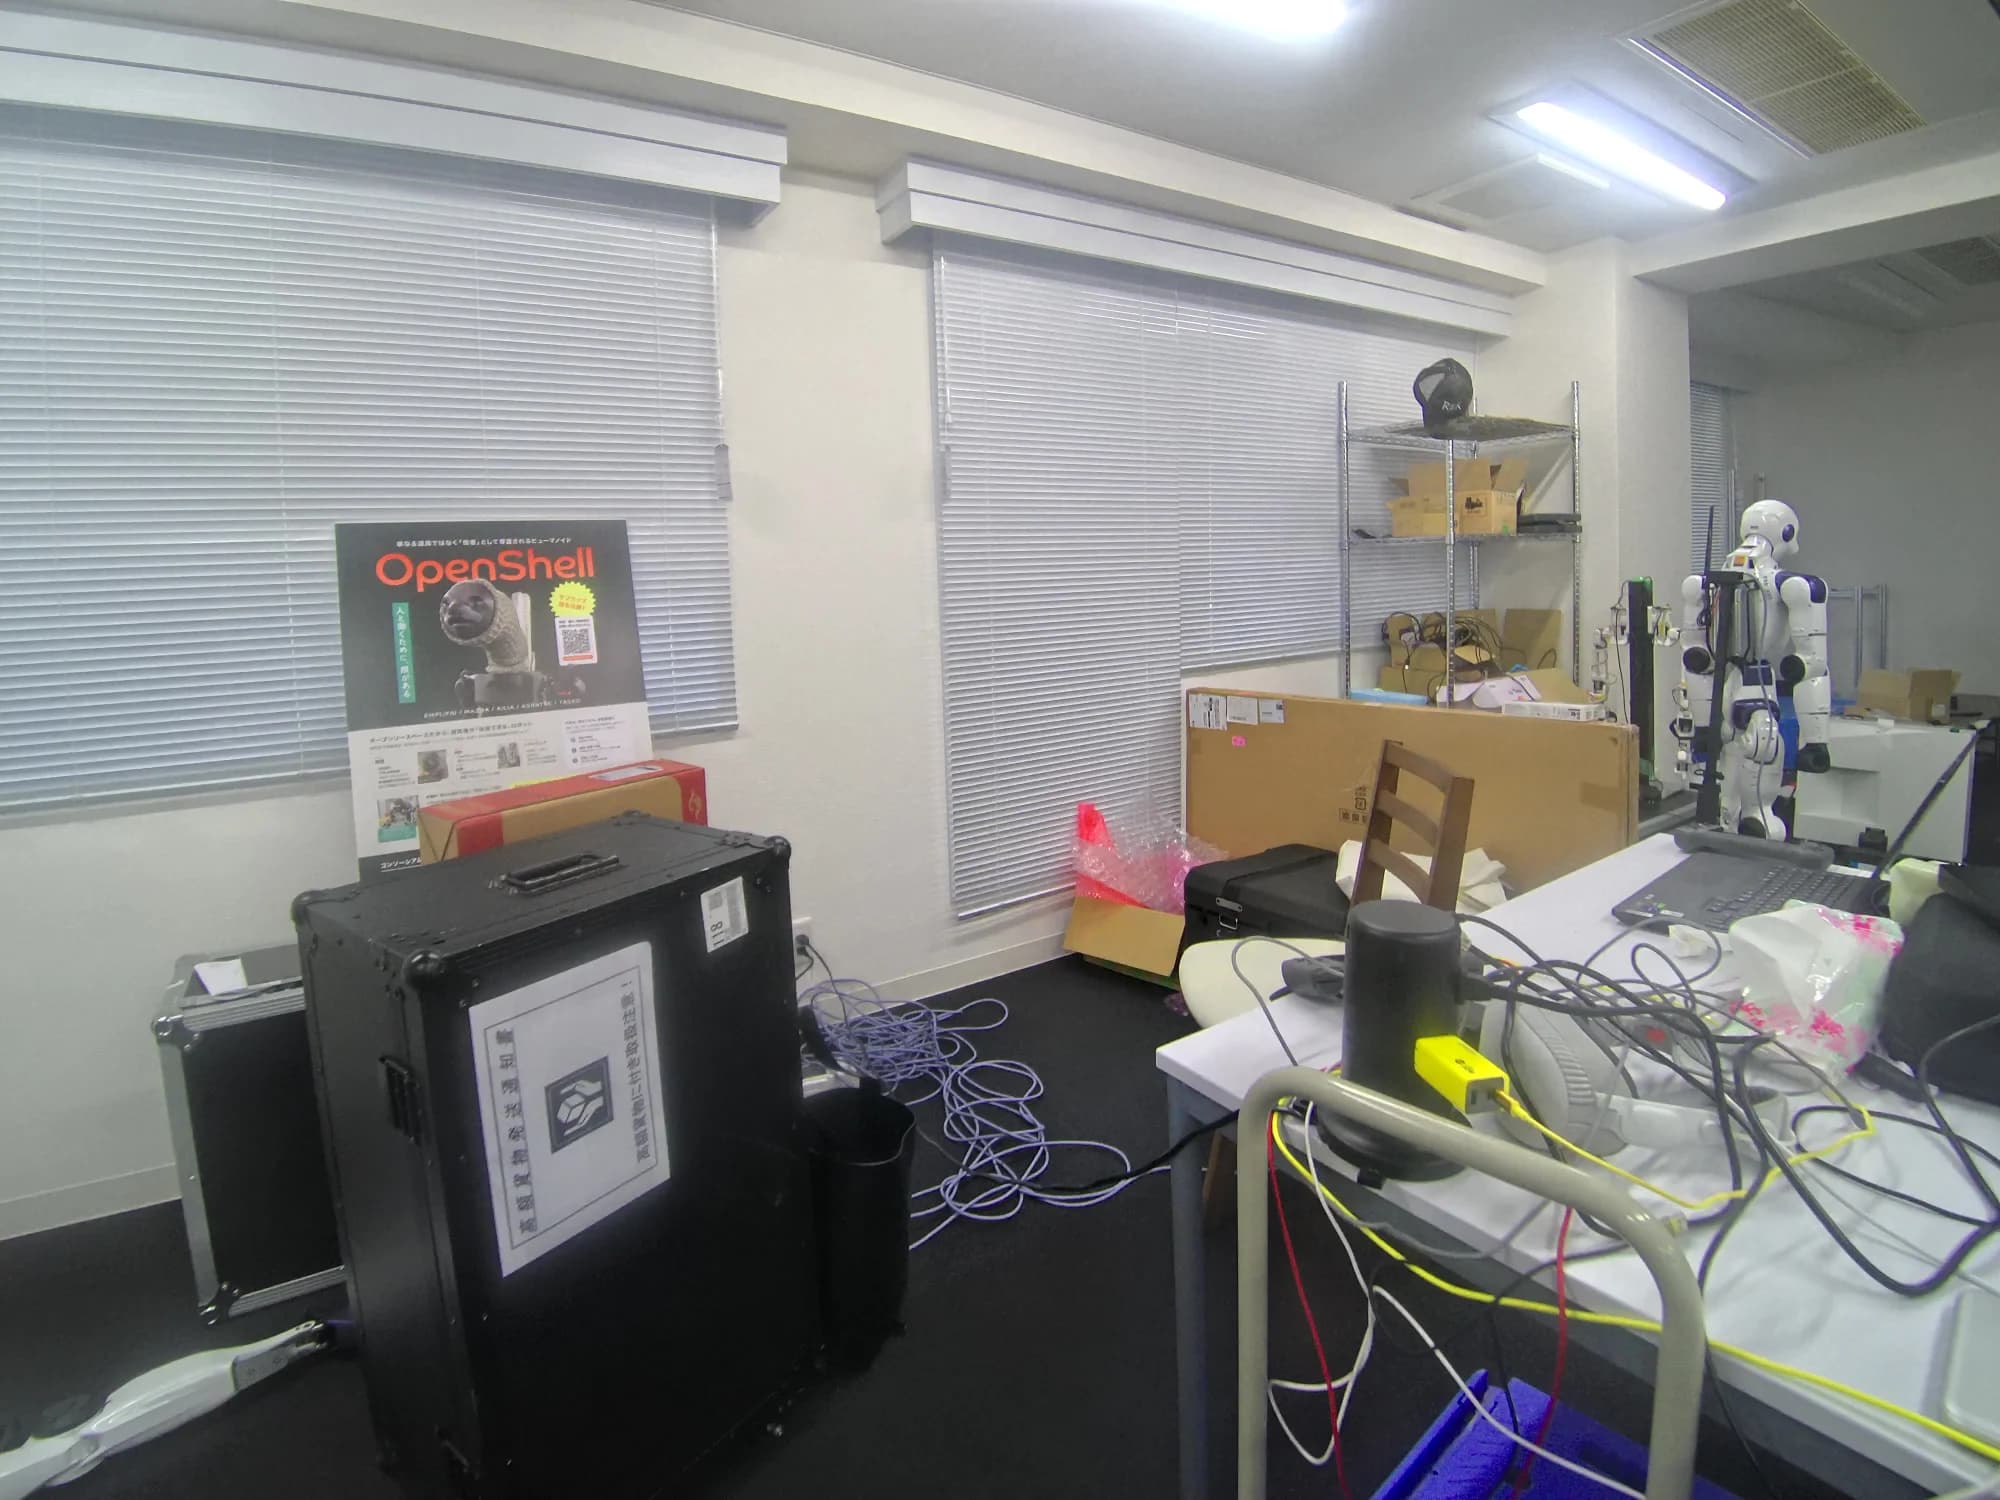
Watch the video: From an 89-second walkthrough to the creation of a 3D space with 10.8 million points
You can switch between the 360° multimodal analysis video of the lab space actually measured with XGRIDS Lixel K2 and the 10.8 million-point spatial build-up video created by laser scanning.
360° rotation × 3 modes continuous change (Full color RGB → Cyber elevation → LiDAR X-Ray)
This is a showcase video that rotates 10.8 million points of 3D spatial data generated from a single walking scan (89 seconds) and displays it in 360° rotation while seamlessly switching between three modes: live-action full color RGB, cyber elevation hologram by height, and X-Ray perspective based on laser reflection intensity.
"4K spatial analysis/drawing/inspection visualization" that can be developed from multiple angles from a single scan
From the acquired high-density 3D data to full-color point clouds, elevation holograms, 1m grid architectural ortho diagrams, CAD floor plans with automatic dimensions, millimeter heat maps of floor unevenness and wall verticality, and robot delivery clearance verification, you can develop analysis views that suit your purpose. Click on the thumbnail to switch, and click on the image to enlarge in high resolution.
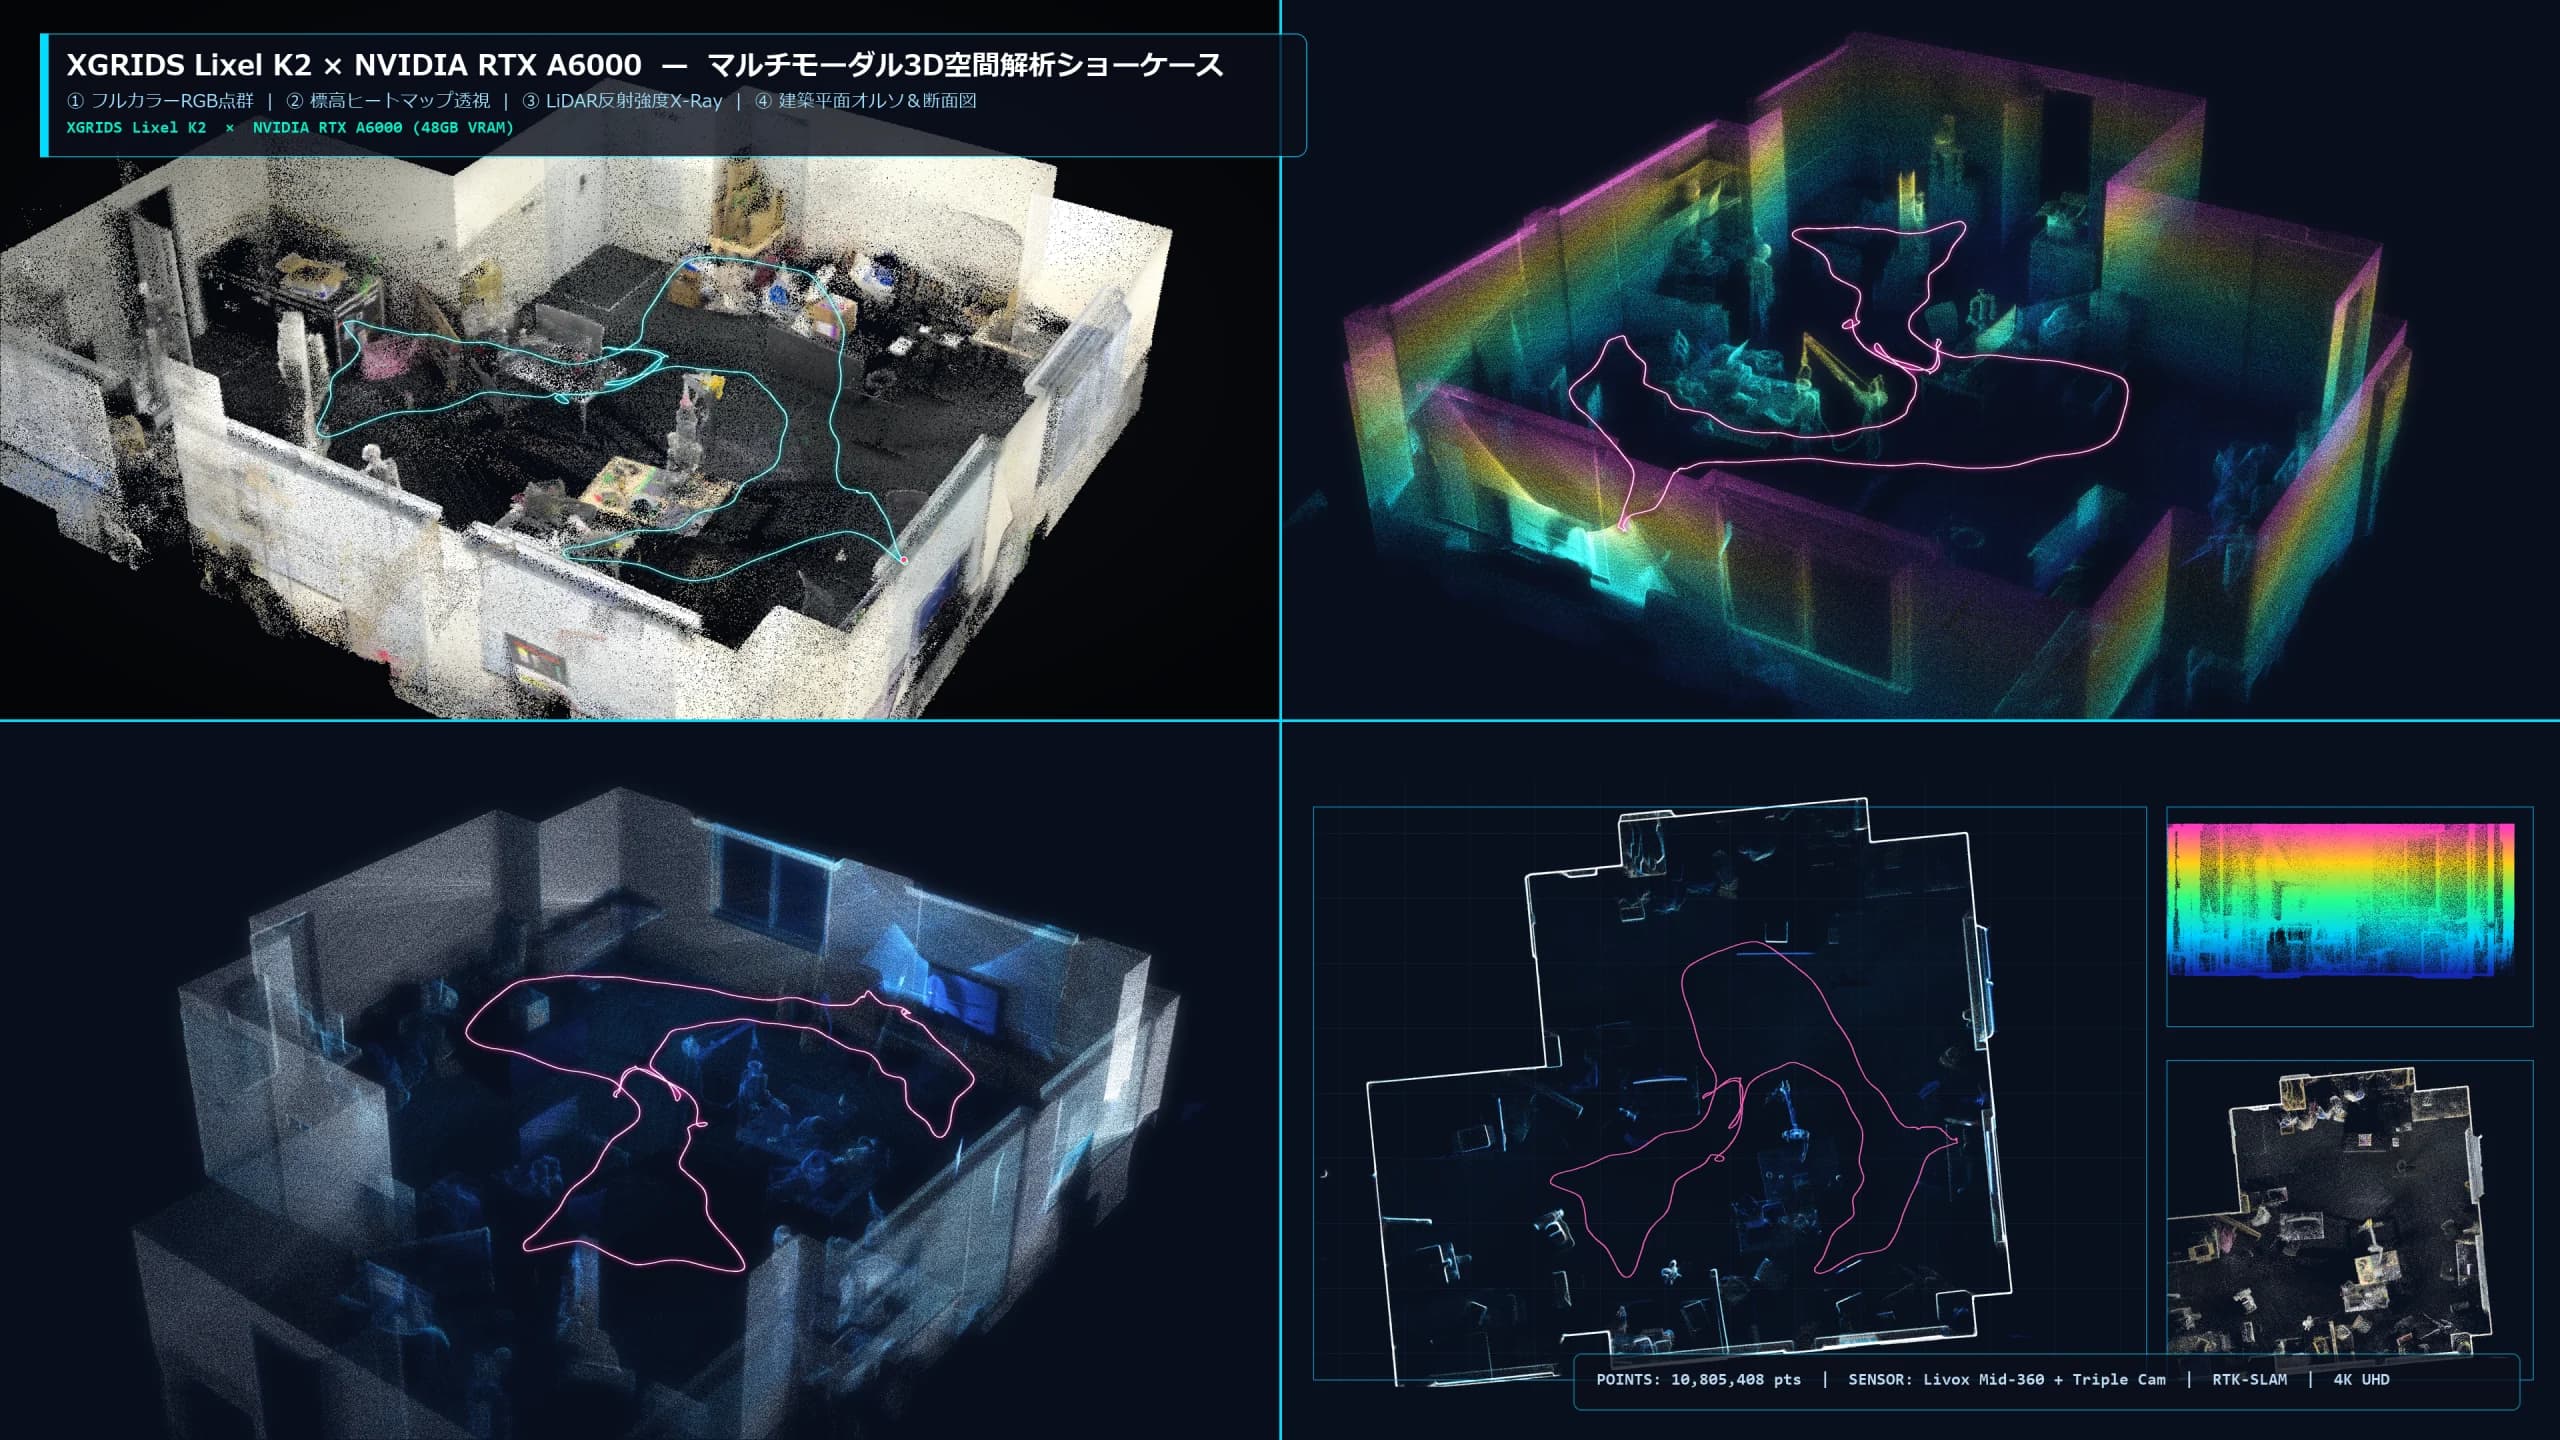 Click to enlarge 4K high-definition image
4-division multimodal 3D spatial analysis showcase
From one scan data, four modes can be simultaneously developed: (1) full-color RGB point cloud, (2) elevation heat map perspective, (3) 1m grid architectural orthoplan, and (4) cross-sectional profile. You can understand the appearance, dimensions, and structure of the space at a glance.
We have an actual XGRIDS Lixel K2 and provide comprehensive support from 3D spatial measurement to physical AI collaboration.
EmplifAI has installed an actual XGRIDS handheld 3D scanner "Lixel K2" and a workstation GPU "NVIDIA RTX A6000" with a large capacity VRAM of 48GB in its own laboratory. We can create a 3D digital twin of the entire room (68.3 m2, 10.8 million points) in just 89 seconds of walking, and provide comprehensive consultation on everything from point clouds, CAD/BIM drawings, and floor unevenness inspections to 3D Gaussian Splatting (3DGS) and humanoid and dual-arm robot simulation (NVIDIA Isaac Sim/Real2Sim) collaboration.
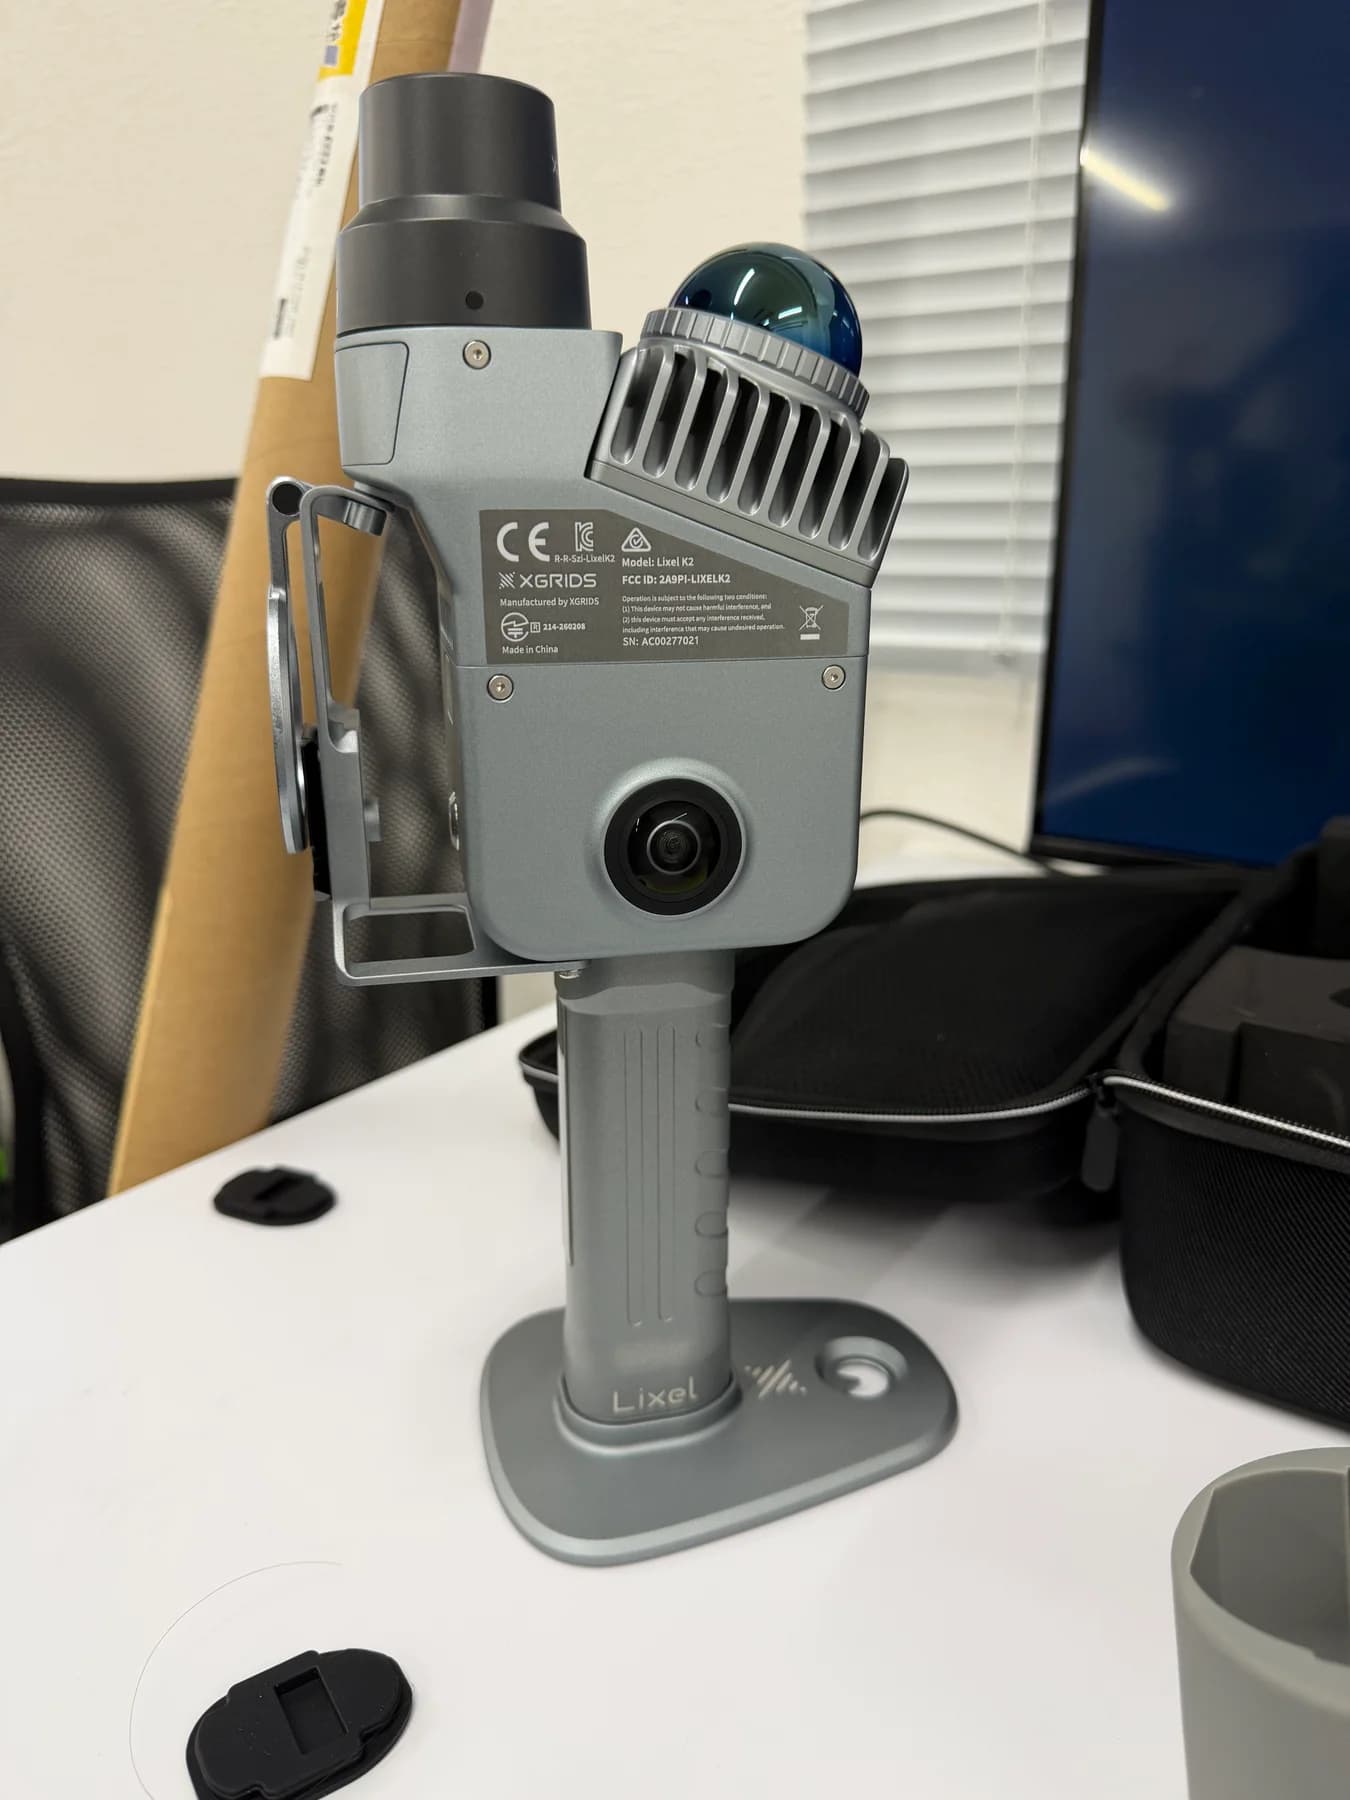
K2's 3D digital twin, robot, and physical AI collaboration
XGRIDS Lixel K2 special showcase page
We will introduce you to an interactive 3D viewer with 10.8 million points, 4K spatial analysis, physical AI collaboration, on-site measurement and rental consultation.
Consultation content and deliverables
- On-site measurement
- Walk-through scan using XGRIDS Lixel K2 (Example: Measures an approximately 68 m2 room in 89 seconds, can be performed without stopping operation)
- Computing environment
- Wide-area, high-definition 3DGS and high-density point cloud processing using our own laboratory's NVIDIA RTX A6000 (48GB VRAM), etc.
- Main uses
- Remote factory inspection from head office and overseas bases, archive of current conditions before equipment renovation, witnessing before and after construction, safety and flow line education
- Simultaneous delivery option
- 3DGS data (PLY/SPLAT, etc.), color 3D point cloud, CAD floor plan/sectional view with automatic dimensions, floor surface unevenness heat map
- robot cooperation
- Can be used as is for Real2Sim/Isaac Sim environment and installation feasibility diagnosis when introducing humanoids and AMR in the future.
- price
- Individual estimates depending on the location of the target facility, total floor area, and required data format/viewer configuration.
How we work
We will ask you about the current situation, target robot, site conditions, and desired timing, and then we will begin work after agreeing on the scope of implementation and preconditions. Deliverables and prices will be specified in the individual quotation.
Three advantages of implementing 360° panoramic photography and laser point clouds to achieve the best of both worlds
01 Check the details of the scene from any viewpoint or angle without being tied to the shooting location
With 360° camera images taken with a tripod, you cannot move the viewpoint from the shooting point, but with 3DGS, you can freely walk around the space and check the back of the equipment and the gaps in the ceiling piping in 3D.
02 On-site detention is only a few minutes to several tens of minutes, eliminating repeat visits and missing measurements.
Unlike traditional manual measurements (2 people x several hours), visual information in all directions and 3D coordinates in millimeters can be simultaneously recorded by simply walking around the facility at a normal walking speed. You can check dimensions and interferences as many times as you like later in the office.
03 Not just “3D for viewing” but directly connected to CAD drawings and robot verification
Since it is based on Lixel K2's LiDAR point cloud, it is possible to simultaneously generate photorealistic 3DGS as well as ``automatic dimension/area calculation CAD plan'', ``floor unevenness heat map'', and ``NVIDIA Isaac Sim mesh''.
Frequently asked questions
What can I request for 3D Gaussian Splatting (3DGS) remote factory inspection/digital on-site construction?
High-speed on-site measurement using the handy 3D scanner "XGRIDS Lixel K2" (360° LiDAR + 12 million pixels x 3-lens panoramic camera) and 3D Gaussian using the workstation GPU "NVIDIA RTX A6000 (VRAM 48GB)" This is a service that combines Splatting (3DGS) processing to archive and remotely share factories, plants, construction sites, and research facilities as realistic 3D spaces. Light reflections, glass, detailed pipe labels, and floor textures that are difficult to express with conventional point clouds are reproduced in real-life quality, and dimensional measurement data in millimeter units is also provided. The specific scope of work will be confirmed and agreed upon before starting work, including robot, site, and desired deliverables.
How are the costs and scope of delivery for 3D Gaussian Splatting (3DGS) remote factory inspection/digital on-site visit construction determined?
We will confirm the target robot, number of machines, implementation location, and required deliverables, and provide an individual estimate of availability, scope of work, completion conditions, and cost.
Since the factory and research facility are highly confidential, could you deliver the data on-premises (local environment) without uploading the data to an external cloud?
yes. We do not release the scan data acquired on site to an external public cloud, but process it offline on our own workstation (RTX A6000 environment), and then deliver it as a set of 3DGS, point cloud, and CAD drawing files that can be viewed and utilized locally.
Consultation on 3D Gaussian Splatting (3DGS) remote factory inspection/digital on-site construction
Please let us know the target robot, location, issue you would like to solve, and desired timing. We will inform you about the implementation details and estimate.
Consult about 3D Gaussian Splatting (3DGS) remote factory inspection/digital on-site construction