Isaac Sim environment construction from 3D scanMeasure the site and create an environment to start robot verification with Isaac Sim.
Using 3D scan data of factories, warehouses, etc. as a starting point, we support organizing point clouds and meshes, checking coordinates and scale, and creating environment models to be used in Isaac Sim. We confirm in advance the robot and sensor model, the behavior you want to check in the simulation, and the required level of detail, and agree on the supported data format and scope of delivery.
Consult about building Isaac Sim environment from 3D scan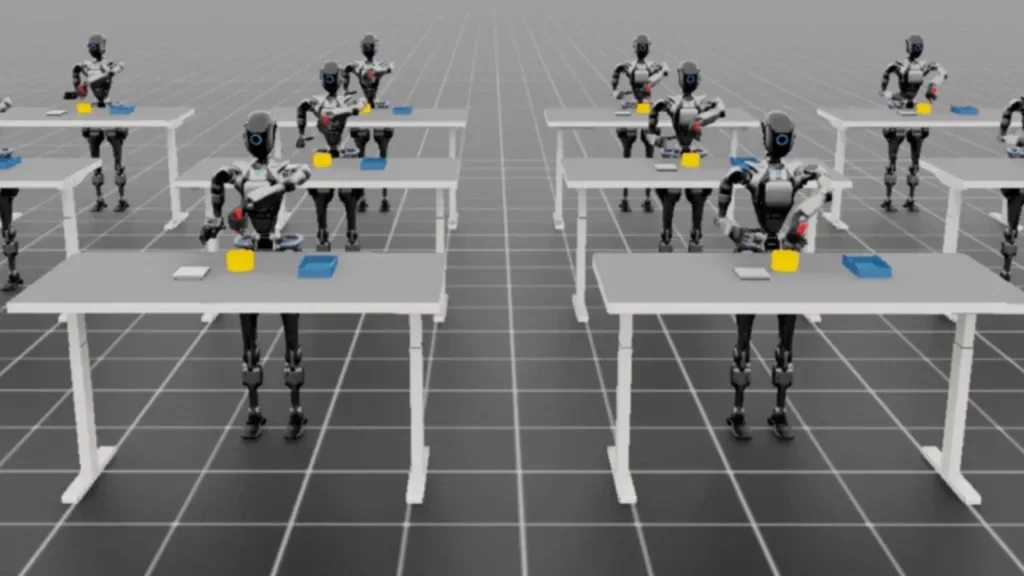
Consultation content and deliverables
- input
- Point cloud, mesh, or CAD; confirm format and coordinate frame
- environment
- Check the version of Isaac Sim, GPU, and robot model
- model
- Agree on shape, collision, and physical conditions necessary for verification purposes
- Deliverables
- Agreed environment model, startup settings, verification method/constraints
- price
- Individual estimates depending on measurement range, data status, and model detail level
How we work
We will ask you about the current situation, target robot, site conditions, and desired timing, and then we will begin work after agreeing on the scope of implementation and preconditions. Deliverables and prices will be specified in the individual quotation.
Frequently asked questions
What can I request for Isaac Sim environment construction from 3D scanning?
Using 3D scan data of factories, warehouses, etc. as a starting point, we support organizing point clouds and meshes, checking coordinates and scale, and creating environment models to be used in Isaac Sim. We confirm in advance the robot and sensor model, the behavior you want to check in the simulation, and the required level of detail, and agree on the supported data format and scope of delivery. The specific scope of the project will be agreed upon before the start of the project after confirming the robot, site, and desired deliverables.
How are the costs and scope of delivery for building an Isaac Sim environment based on 3D scanning determined?
We will confirm the target robot, number of machines, implementation location, and required deliverables, and provide an individual estimate of availability, scope of work, completion conditions, and cost.
Consultation on building Isaac Sim environment from 3D scanning
Please let us know the target robot, location, issue you would like to solve, and desired timing. We will inform you about the implementation details and estimate.
Consult about building Isaac Sim environment from 3D scan