
OpenArm developmentThe arms we put on our own robot, taken through to training.
OpenShell, EmplifAI's dual-arm mobile humanoid, uses OpenArm 01 for its arms. Building it, demonstrating through teleoperation, and feeding those recordings into training: we have been through that whole route in house. The same route, on your OpenArm. We take on imitation learning and VLA implementation, together with the data collection setup they depend on.
Discuss OpenArm development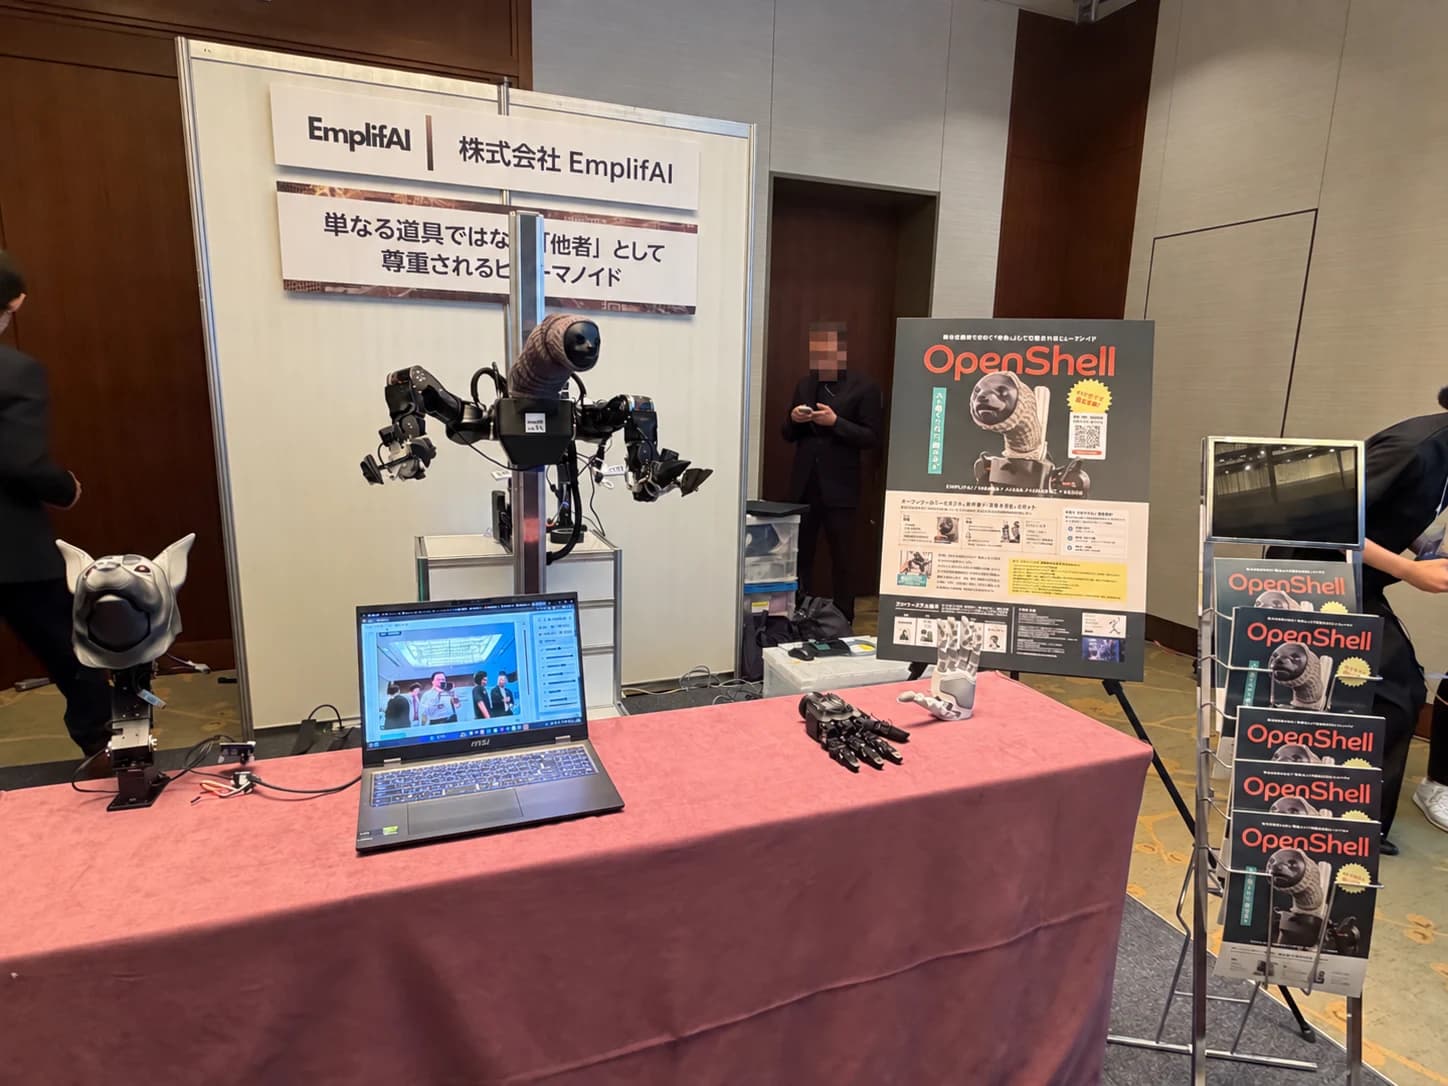
The arms are obtainable. What stops you is what comes after
OpenArm is open source, so getting hold of the design and building it is something many labs and development teams manage on their own. What stops them is the next step. The arms move, but nothing settles what to record, how many times, and under what conditions for training to work. The data piles up, and then it fails to reproduce on the robot.
EmplifAI adopted OpenArm 01 for OpenShell's arms, building a dual-arm configuration of seven axes per arm plus one gripper axis. Decisions down to mounting the arms the opposite way round so the elbows come forward were settled on the robot itself. This is a team that has been through the whole stretch: assembly, demonstration by teleoperation, synchronised recording, training, and evaluation on the robot.
That is why enquiries fit best at the stage of "we have the arms but cannot get to training". If you have decided which task to target, we define the data conditions and the shape of the collection setup with you from there.
What we can take on
Training, and the data collection setup it depends on, are the focus. We also take on work on the robot itself, to the extent training requires it.
Implementing imitation learning
We train OpenArm's motions from human demonstrations: separating out the target task, implementing the training, and evaluating on the robot. We work with LeRobot-based configurations.
Implementing VLA
Implementation of VLA, connecting visual and language understanding to motion generation. We cover the ground where motions cannot be written out, such as tasks where the shape or position of the object changes every time.
Building the data collection setup
From deciding what to record, under which conditions and how many times, through to building the setup itself. We get you to a state where video and motion can be recorded in sync.
Demonstration setup by teleoperation
The operating setup used to capture demonstration data. We have implementation experience with force feedback through bilateral leader arms, a precision mode that lowers the motion ratio, and operation with VR controllers.
Assembly, modification and integration
Work on the robot side, to the extent training requires it: adding hands and sensors, wiring and electronics, integration under ROS 2. Parts that each work on their own still fail to work once integrated — that is what a real robot is.
Real-machine evaluation
We put the trained model on the robot and measure success rate and reproducibility. This includes isolating the cause when results that held in simulation fall apart on the robot.
How we work
We start narrowed to a single target task. Widening the scope comes after that.
- 01 Choosing the target task
- We settle on one thing to train. Leaving this broad makes the amount of data needed grow without limit.
- 02 Designing the data conditions
- We decide what to record, how many trials to run, and which conditions to vary. Whether the training works is settled almost entirely here.
- 03 Building the collection setup
- We assemble the setup for demonstration and recording. Whether it is added to your existing environment or built from scratch depends on the situation.
- 04 Collecting the data
- Demonstrate and record. We can take on the collection itself, or hand over the setup for you to run yourselves.
- 05 Training and implementation
- We implement imitation learning or VLA and run the training.
- 06 Evaluation on the robot
- We put it on the robot, measure success rate and reproducibility, and tighten the conditions.
Robots lent as part of development
Only where development is commissioned from us, we also provide a robot for the duration of the trial. You can start from checking on a real robot even before you have one of your own.
We do not offer rental of the robot on its own. Lending the arms alone comes without the support that gets them to a working state, so it would not be of use to you.
Frequently asked questions
Can we talk to you if we do not have an OpenArm yet?
Yes. If you commission development from us, we can provide a robot for the duration of the trial. Please consult us from the choice of configuration onwards. Note that we do not offer rental of the robot on its own.
How much data do we need?
It varies greatly with the target task and the range of conditions that change. A task handling the same object in the same position and one where the shape or position changes every time differ by an order of magnitude. We recommend narrowing to a single target, running a small amount first, and judging from there.
We are already collecting data, but the training does not reproduce.
We take on enquiries from that stage too. We start by separating the causes: insufficient recording conditions, unit-to-unit variation in the robot, or the training side. It sometimes leads to a decision to collect again, so please get in touch early.
Can you work with robots other than OpenArm?
Yes. If the robot is not yet chosen, or you are using something else, please also see the page on VLA and imitation learning development. This page, narrowed to OpenArm, is for those who have already chosen the robot.
Who holds the rights to the trained model and the collected data?
Agreed at the time of contract. The terms differ by arrangement — contract development, joint research and so on — so please raise it at the planning stage.
Enquiries about OpenArm development
Tell us the task you want learned and the state of the robot and setup you have. Whether you have the arms but cannot get to training, or are still about to obtain a robot, either is fine. The work is handled by a team that has been through the same stretch with its own humanoid.
Discuss OpenArm development