
Multimodal AI (VLM) × Humanoid autonomous grasping/picking PoCAI understands and grasps the situation from the camera's visual information, without relying on hard-coded trajectories.
This is an actual PoC service that combines the latest multimodal AI (VLM / VLA) such as Gemini 4 Argon with Unitree G1 (5-fingered hand configuration) and a dual-arm robot to recognize the position, posture, and surroundings of objects from camera images and autonomously grasp and place them (pick and place). Even if the object is repositioned and repositioned each time, the AI generates the grasping motion based on visual judgment, making it possible to quickly conduct "one-step automation feasibility verification" before collecting data for hundreds to thousands of imitation learning sessions.
Consult about multimodal AI (VLM) x humanoid autonomous grasping/picking PoC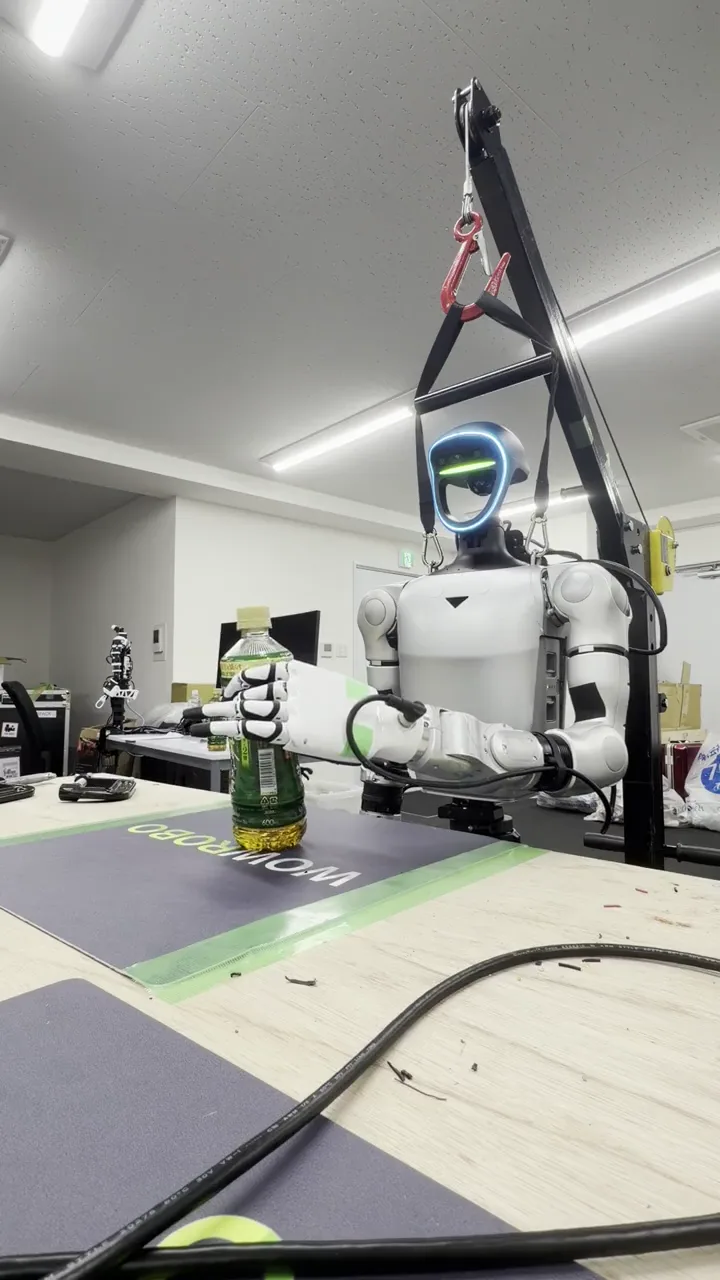
Consultation content and deliverables
- Validationrobot
- Select from Unitree G1 (5 finger hand/gripper configuration), AgiBot G2, OpenArm dual arms, RealMan, etc.
- AI/recognition platform
- Visual recognition/spatial reasoning using the latest VLM such as Gemini 4 Argon + inverse kinematics (IK)/skill control or VLA policy
- Example of target task
- Recognizes beverage bottles, resin parts, boxes, tools, etc., grasps them, maintains them upright, transports them, and places them in designated trays.
- Demonstration step
- ① Grasping test at Yushima Lab using object samples ② Evaluation of resistance to positional changes and illumination changes ③ Design of local environment and next stage (data collection, dedicated learning)
- Deliverables
- Actual machine verification video, analysis report of success rate, cycle time, failure factors, technical requirements definition for full-scale implementation
- price
- Individual estimates depending on the type of object, usage robot, verification period and location
How we work
We will ask you about the current situation, target robot, site conditions, and desired timing, and then we will begin work after agreeing on the scope of implementation and preconditions. Deliverables and prices will be specified in the individual quotation.
Dramatically shorten PoC startup with the "Visual → Behavior Conversion" architecture proven in our own laboratory
01 Compatible with "variations in placement" that cannot be handled with fixed coordinate programs
With conventional teaching control, if the object shifts by just a few centimeters, it will miss the swing, but with VLM cooperation, the 3D position of the object and grasping approach are inferred from the camera image each time. You can verify that the object will follow and re-grasp even if it is placed again.
02 Quickest way to determine whether it can be grasped as hardware before collecting large amounts of data
Before investing in collecting thousands of episodes of imitation learning data from the beginning, you can use VLM + skill control to determine whether the robot's current reach, gripping force, and camera angle of view can handle the part at a small cost and in a short period of time.
03 Seamless transition from VLM inference to dedicated VLA (π0.5/GR00T/ACT etc.)
After confirming the feasibility of the process through zero-shot/small-shot verification using VLM, remote operation data is collected using the same robot environment, and the process is gradually upgraded to a dedicated VLA model and imitation learning policy that operates at high speed and offline.
NVIDIA GEAR Sonic × Unitree G1: Real robot demonstration
We ran NVIDIA GEAR Sonic on a Unitree G1 robot and verified its operation. Watch the video to see the demonstration.
Gemini 4 Argon × Unitree G1: Turning Vision into Action
Unitree G1 just picked up a plastic bottle using Gemini 4 Argon. No hard-coded motions. Just AI turning vision into action. The future of robotics is getting real.
Even when the bottle is moved and placed again, the AI visually understands the scene and generates the grasping motion. We provide Physical AI and VLA implementation on the Unitree G1 as well as custom PoC and verification development tailored to your operations.
Frequently asked questions
What can I request with Multimodal AI (VLM) x Humanoid Autonomous Grasping/Picking PoC?
This is an actual PoC service that combines the latest multimodal AI (VLM / VLA) such as Gemini 4 Argon with Unitree G1 (5-fingered hand configuration) and a dual-arm robot to recognize the position, posture, and surroundings of objects from camera images and autonomously grasp and place them (pick and place). Even if the object is repositioned and repositioned each time, the AI generates the grasping motion based on visual judgment, making it possible to quickly conduct "one-step automation feasibility verification" before collecting data for hundreds to thousands of imitation learning sessions. The specific scope of work will be confirmed and agreed upon before starting work, including robot, site, and desired deliverables.
How are the costs and delivery scope of the multimodal AI (VLM) x humanoid autonomous grasping/picking PoC determined?
We will confirm the target robot, number of machines, implementation location, and required deliverables, and provide an individual estimate of availability, scope of work, completion conditions, and cost.
Could you send your own parts and product samples to the lab and see if they can be grasped by Unitree G1, etc.?
yes. After confirming the dimensions, weight, and material of the object (presence of damage or liquid leakage) in advance, please send the sample to EmplifAI Lab in Yushima, Tokyo, and we will conduct a gripping test using our Unitree G1 or dual-arm machine, and report the video and evaluation data.
Multimodal AI (VLM) × Humanoid autonomous grasping/picking PoC consultation
Please let us know the target robot, location, issue you would like to solve, and desired timing. We will inform you about the implementation details and estimate.
Consult about multimodal AI (VLM) x humanoid autonomous grasping/picking PoC