
EmplifAI develops "OpenShell", a dual-arm mobile humanoid that interacts with people through facial expressions
EmplifAI Co., Ltd. (Headquarters: Bunkyo-ku, Tokyo, President: Hiroyuki Osone) has developed a humanoid called "OpenShell" that combines dual-arm work and wheel movement with facial and vocal communication.
This robot is a robot proposed by the AI Robot Association (AIRoA) to the "Domestic General-Purpose Robot Development Competition" held as part of a project commissioned by NEDO (New Energy and Industrial Technology Development Organization).
Equipped with a total of 28 axes in the head, arms, grippers, and trolley, it supports research and development of physical AI and interpersonal interaction. Based on open source hardware, we are accepting inquiries regarding purchase, joint development, and interviews as a platform that can expand the body and intelligence to suit research purposes.
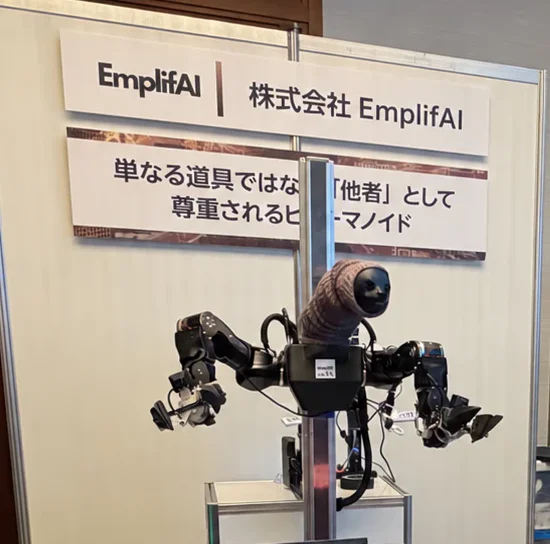
Development background: Researching both work ability and how to interact with people
Robots that work in the same space as humans must not only be able to carry and manipulate objects, but also be able to easily understand their movements and intentions. OpenShell was developed based on the concept of "having a face to work with people" to test both work ability and communication.
Main features of OpenShell
1. The head conveys intentions through facial expressions and facial orientation
The head has a sloth motif and is equipped with a total of 4 axes: pan/tilt, mouth corner, and lip sync. You can study how humans and robots interact, such as facial orientation, facial expressions, direction of attention through voice, and indication of movement initiation. The head design is by artist Takayuki Todo.
The head can be replaced and expanded, and is equipped with stereo camera. It supports stereoscopic viewing with VR goggles and 3D displays, and the camera, display, and facial expression mechanism can be customized to suit your needs. Facial expressions and intention presentation are HMI (human-machine interface) independent of safety functions.
2. A total of 28 axes, combining dual arms and omnidirectional movement.
OpenArm 01 is used for the arms and TidyBot++ is used for the trolley. The arms are attached so that the elbows are in front, making it easier to work in front. You can hold a 2L plastic bottle with one hand.
- Head: 4 axes (pan/tilt, mouth corner, lip sync)
- Arm: 7 axes x 2 = 14 axes
- Gripper: 1 axis x 2 = 2 axes
- Trolley: 8 axles (4 wheels x 2 axles for steering and wheel drive)
- Total: 28 axes
The trolley has 8 drive axes that allow it to move in 3 degrees of freedom: back and forth, left and right, and turning. If equipped with 3D LiDAR as an option, it can also support autonomous movement. It can be used for research that combines dual-arm operation and movement.
3. Remote control with force feedback and VR
Compatible with force feedback by bilateral leader arms. A precision mode that lowers the robot's movement magnification relative to the operation can be used to verify detailed work. It also supports operation with a VR controller.
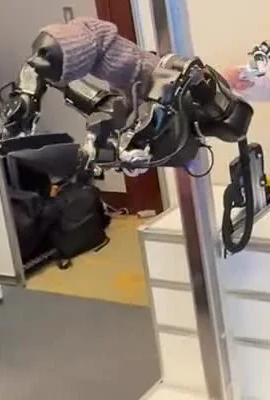
4. Expandable research and development platform compatible with ROS 2 and LeRobot
It is compatible with ROS 2 / SDK / LeRobot and has a configuration that allows you to connect your own VLA, imitation learning, reinforcement learning (RL), and various sensors. You can replace or add heads, hands, and AI, and verify controls and hardware according to your research theme.
Transfer work and interaction data to further learning
Through remote-controlled work demonstrations and synchronous recording of visual, behavioral, dialogue, and non-verbal information, we will study not only movements but also the presentation and response of intentions. The collected data will be used to evaluate, learn, and improve work abilities and interpersonal interactions, supporting research on physical AI that involves collaboration with people.
Future outlook
EmplifAI will gradually open up publicly available ROS 2 packages and interfaces, and work with the research community to improve and expand OpenShell. Through joint development with research institutions and companies, we aim to create a platform that allows for integrated research into the body, intelligence, and how people interact.
Product information/inquiries
If you are considering introduction, research use, joint development, or reporting, please let us know the purpose, desired configuration, and timing.