Unitree G1 × Gemini Argon experimental code has been released with Apache-2.0
EmplifAI Co., Ltd. has released the experimental code "G1/ARGON" that connects Unitree G1 and Gemini Argon under Apache-2.0 license. This is a public experiment that shares the connection between the LLM agent and the robot control, along with reproduction steps, constraints, and videos.
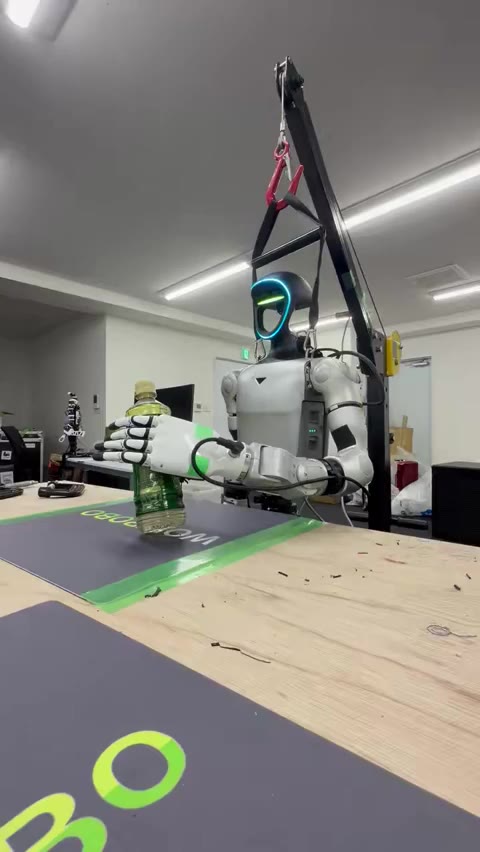
Actual machine video: Transporting bottles while standing upright
Using the left arm of the Unitree G1 supported by a hanging device and the Inspire Hand, we conducted an experiment in which we lifted and carried a plastic bottle while keeping it upright. You can see a video of the robot in the X post by representative Hiroyuki Osone. It is not a benchmark for success rate or reproducibility in different environments.
English web console that you can try with your own API key
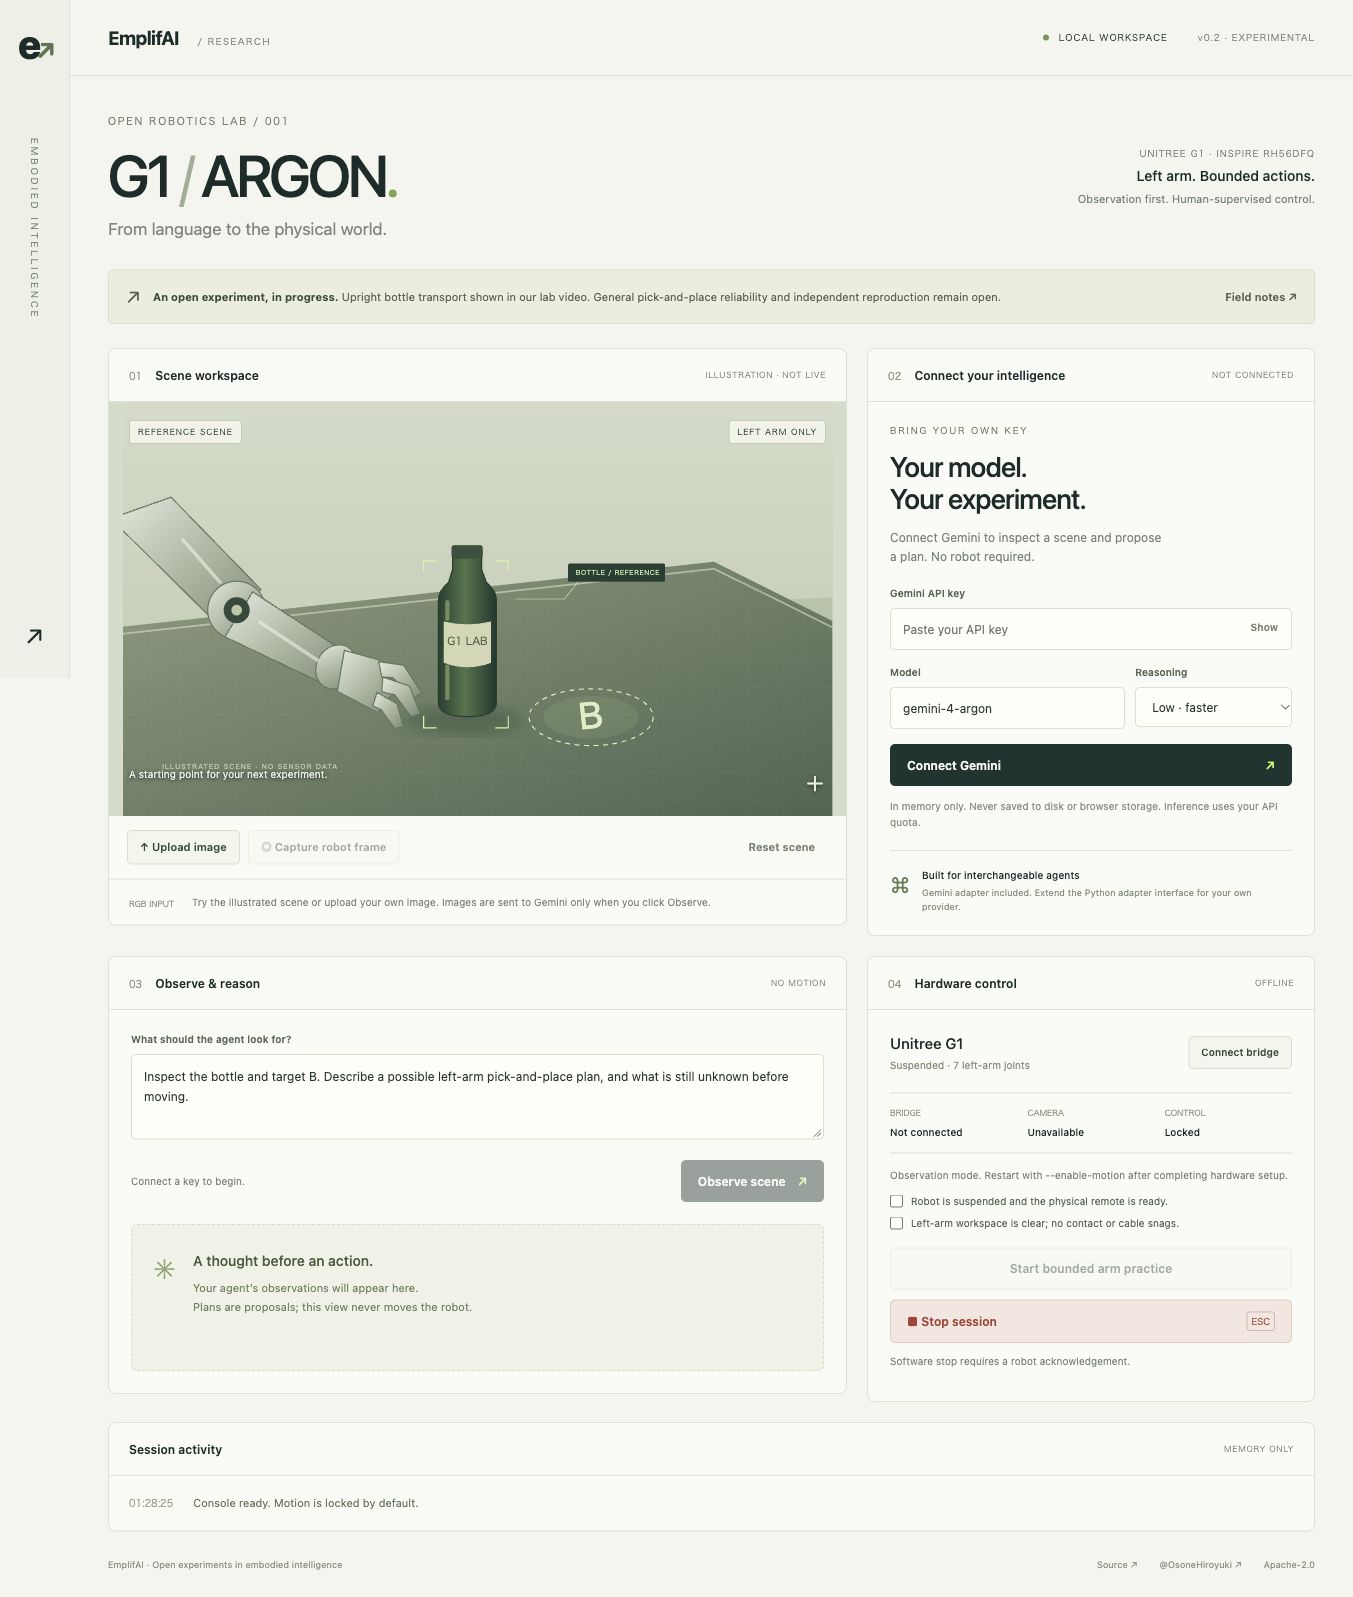
Open your local web app with a single Python startup command, enter your Gemini API key, and try out image recognition and plan suggestions. Image observation is available without robots and does not store API keys in files or browser storage. Separate hardware setup is required for robot control.
What we accomplished and what we will verify next
The public web app starts in observation mode. Small left-arm trials require explicit hardware setup and operator checks; the public console does not launch the legacy grasp-and-place macro. Camera and hand calibration, grasp detection, and reproducibility across conditions remain open work.
We have an adapter interface for adding providers, and currently include an implementation for Gemini. We welcome contributions to support other agents, evaluations using recorded images, and reports of reproduction on actual devices.
As open source for commercial use
EmplifAI's original code is released under Apache-2.0, including for commercial use. External SDKs, robot models and API services retain their own terms. Contributors are asked to add a Signed-off-by trailer certifying the DCO. This is an independent EmplifAI project, not an endorsement or guarantee from the hardware or model providers.
GitHub: View source code, startup procedure, and actual sample
Hiroyuki Osone's X: Watch the actual video
If you are considering support for implementation on actual machines, custom task development, or joint evaluation, please contact us with the target machine and task.